1
Turbo PMAC Software Reference
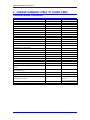
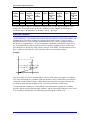
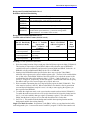
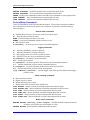
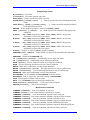
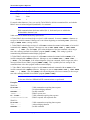
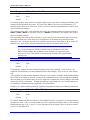
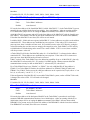
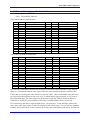
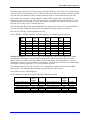
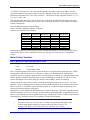
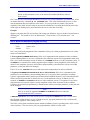
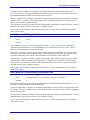
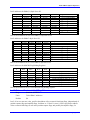
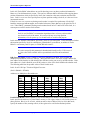
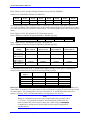
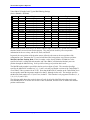
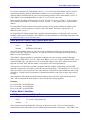
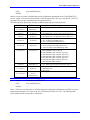
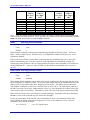
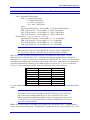
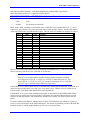
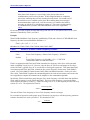
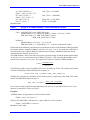
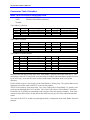
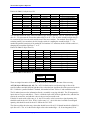
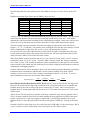
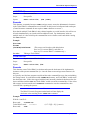
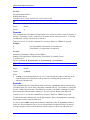
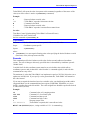
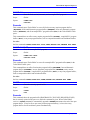
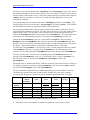
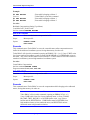
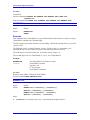
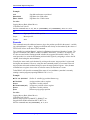
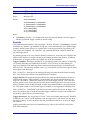
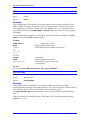
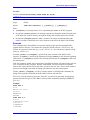
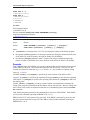
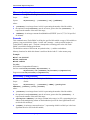
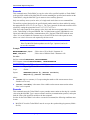
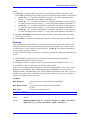
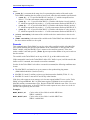
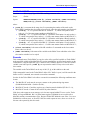
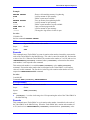
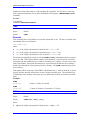
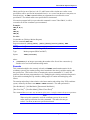
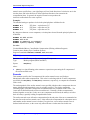
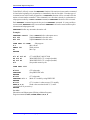
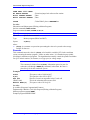
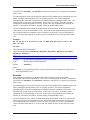
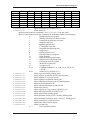
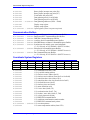
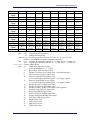
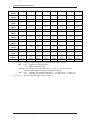
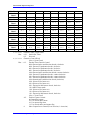
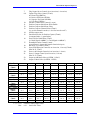
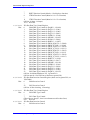
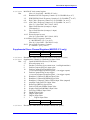
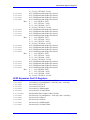
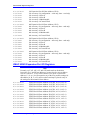
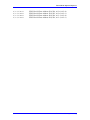
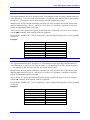
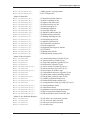
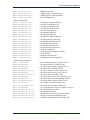
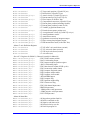
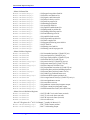
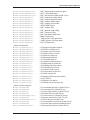
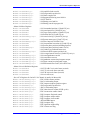
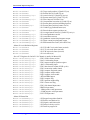
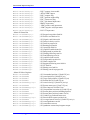
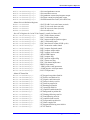
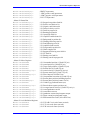
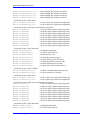
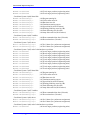
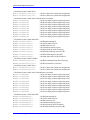
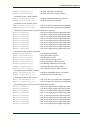
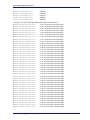
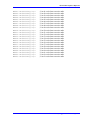
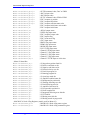
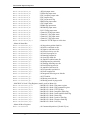
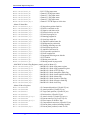
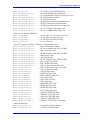
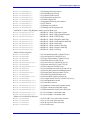
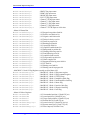
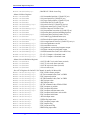
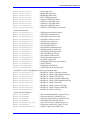
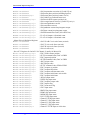
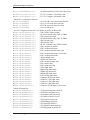
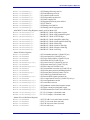
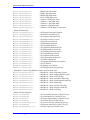
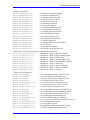
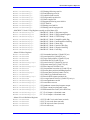
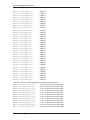
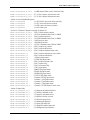
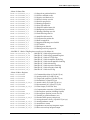
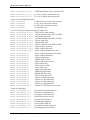
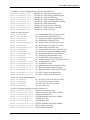
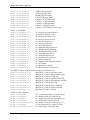
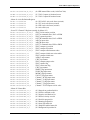
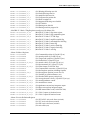
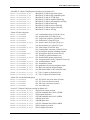
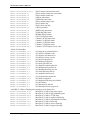
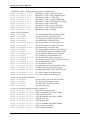
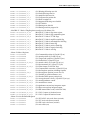
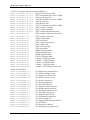
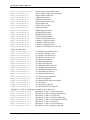
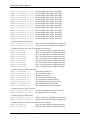
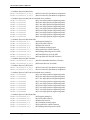
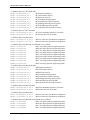
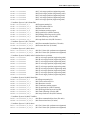
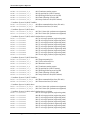
Ixx81 for MACRO Absolute Position Reads
(Ixx91=$720000 - $740000)
Addresses are MACRO Node Numbers
MACRO
Node
Number
Ixx81 for
MACRO
IC 0
Ixx81 for
MACRO
IC 1
Ixx81 for
MACRO
IC 2
Ixx81 for
MACRO
IC 3
0
1
4
5
8
9
12
13
$000100
$000001
$000004
$000005
$000008
$000009
$00000C
$00000D
$000010
$000011
$000014
$000015
$000018
$000019
$00001C
$00001D
$000020
$000021
$000024
$000025
$000028
$000029
$00002C
$00002D
$000030
$000031
$000034
$000035
$000038
$000039
$00003C
$00003D
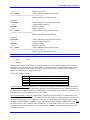
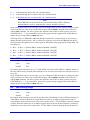
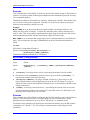
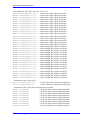
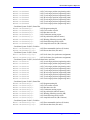
If obtaining the absolute position through a Delta Tau MACRO Station or equivalent, MACRO Station
setup variable MI11x for the matching node must be set properly to obtain the type of information
desired.
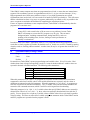
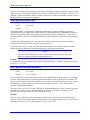
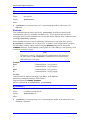
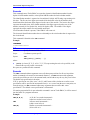
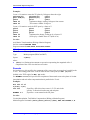
Ixx82 Motor xx Current-Loop Feedback Address
Range:
$000000 – $FFFFFF
Units:
Turbo PMAC Y-addresses
Default:
$0
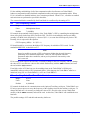
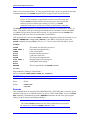
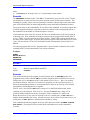
Ixx82 tells Turbo PMAC which addresses to read to get its current feedback values for Motor xx if Turbo
PMAC is closing the current loop for this motor. Turbo PMAC must be performing the commutation for
the motor (Ixx01=1) if it is to close the current loop as well.
A zero value for Ixx82 tells PMAC not to close the current loop for this motor. In this case, PMAC
outputs either one velocity or torque command value (Ixx01 bit 0 = 0), or two phase-current command
values (Ixx01 bit 0 = 1), usually represented as analog voltages.
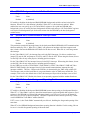
A non-zero value for Ixx82 automatically triggers current loop execution in the phase interrupt using the
current values found in the registers specified by Ixx82. Typically, these registers are analog-to-digital
converter (ADC) registers in a PMAC2-style Servo IC, or MACRO feedback registers containing copies
of ADC registers in a MACRO Station.
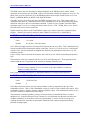
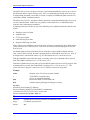
Digital current loop closure on the Turbo PMAC requires a set of three consecutive command output
registers. Generally, this requires writing to either a PMAC2-style Servo IC or a MACRO IC.
When Ixx01 is set to 1, Turbo PMAC performs the phase commutation for this motor, computing two
phase current commands based on the position/velocity servo command and the magnetization current
value. If Ixx82>0, these commands are compared to the two actual current values read from the address
specified by Ixx82, and the next lower address. It executes a PI filter on the current loops and outputs
three voltage command values to the address specified by Ixx02 and the next two higher addresses. These
are typically the PWM commands for the three half-bridges of a brushless motor power stage.
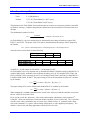
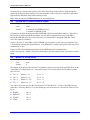
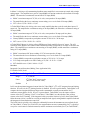
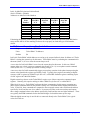
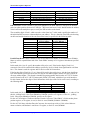
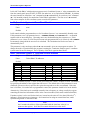
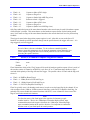
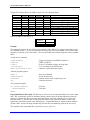
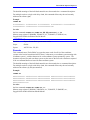
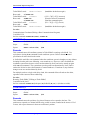
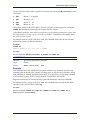
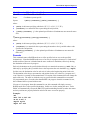
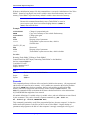
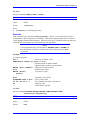
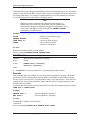
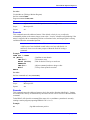
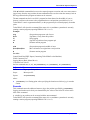
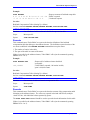
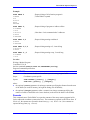
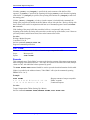
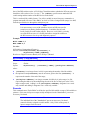
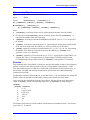
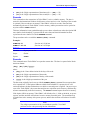
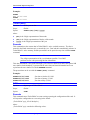
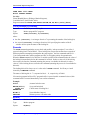
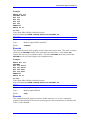
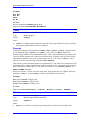
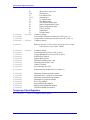
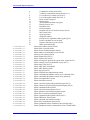
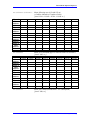
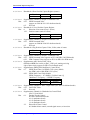
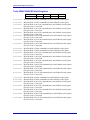
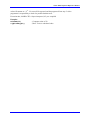
When the digital current loop is used for drives connected directly to the Turbo PMAC2, the typical
values for Ixx82 are:
5-116
Turbo PMAC/PMAC2 I-Variable Specification