1
ECE 477 Final Report
Spring 2013
Abstract
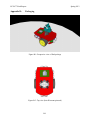
The Infrarat is an autonomous toy car which utilizes an array of infrared and ultrasonic sensors to
navigate the world. The vehicle communicates with an android device to control the vehicle’s
movement mode and transmit infrared (IR) data and send battery information to the user. The
Infrarat has three operating modes: flee, follow, and manual. Flee mode results in the vehicle
running away from people and obstacles at high speed. Follow mode causes the robot to follow a
person using IR heat tracking. Manual mode allows the user to take manual control of the device
with virtual thumb sticks on the Android device.
1.0
Project Overview and Block Diagram
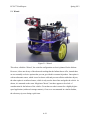
The Infrarat consists of a few critical components: two high speed motors, a swiveling servomounted IR array, and a Bluetooth communication device. The vehicle uses two geared
brushless DC motors to power the wheels and provide high speed navigation. Mounted on the
vehicle is an array of four 16x4 grid IR sensors that supplies the user with directional
temperature information via the I2C protocol. The IR sensors allow the vehicle to track warm
bodies and follow movement with both servo control and vehicle movement. The heavy floating
point calculations involved in parsing the raw temperature data is handled by an
AT32UC3C2256C Atmel microcontroller running full-speed at 60 MHz. In addition to the IR
sensors a pair of ultrasonic sensors mounted on the front and rear of the vehicle allow the vehicle
to detect and avoid nearby objects. The Bluetooth module allows the Infrarat to communicate
with an Android device. This is used to control the three modes and communicate battery charge
levels and display the temperature gradient to the user. The block diagram is displayed below.
A-1