1
Configure XM Module in RSLogix 5000 Software
Chapter 3
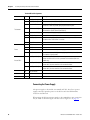
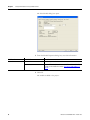
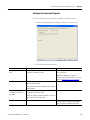
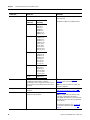
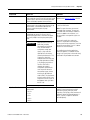
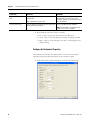
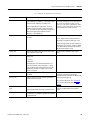
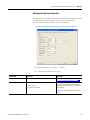
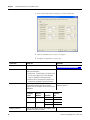
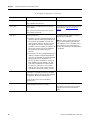
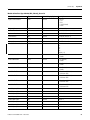
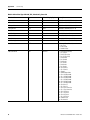
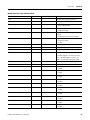
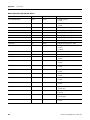
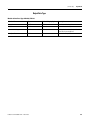
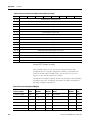
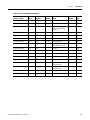
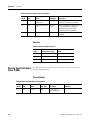
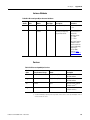
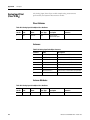
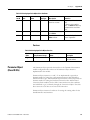
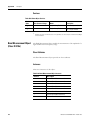
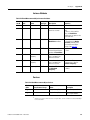
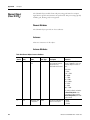
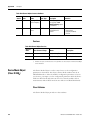
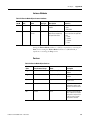
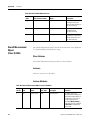
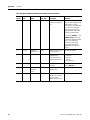
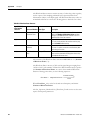
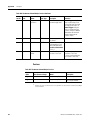
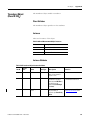
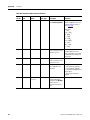
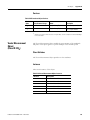
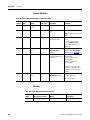
2. Configure the parameters, as necessary.
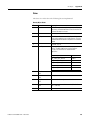
In this field
Values are
Comments
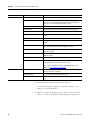
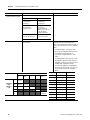
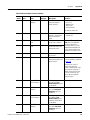
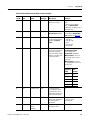
Enable Auto Trigger
Check to enable Auto Trigger mode. The minimum
signal amplitude for triggering is 2 volts peak-to-peak
and the minimum frequency is 6 CPM (0.1 Hz).
Using Auto Trigger mode may cause the
tachometer to trigger on noise if the signal is
very small. For example, you have 1 volt of
noise on a 2 volt signal. To prevent this, make
sure the % noise in the signal is less than the
value entered in the Trigger Hysteresis.
Clear to enable Manual Trigger mode. The value
entered in Trigger Threshold is used as the trigger
point. The minimum signal amplitude for triggering is
500 millivolts peak-to-peak and the minimum
frequency is 1 CPM (0.016 Hz).
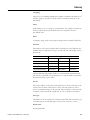
Trigger Hysteresis
Enter the amount of hysteresis around the trigger
threshold.
Enter a value between 0...50.
In Auto Trigger mode, the value entered is a
percentage of the peak-to-peak input signal.
In Manual Trigger mode, the value entered is a
voltage level. The hysteresis voltage is added
to or subtracted from the threshold voltage to
determine the hysteresis range.
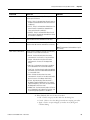
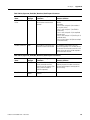
Trigger Level
Enter the signal level to be used as the trigger value
when in Manual Trigger mode.
Trigger Slope
Choose the input signal slope to be used with the
trigger value.
This parameter is dimmed in Auto Trigger
mode.
• Positive
• Negative
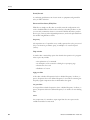
The trigger point of the tachometer defines 0° for
phase measurement. If the tachometer is a square
wave, the phase angles measured will vary by 180°
depending on whether the Trigger Slope is set to
positive or negative.
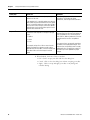
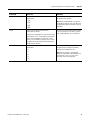
DC High Limit
Enter the maximum expected DC bias voltage from the
transducer.
DC Low Limit
Enter the minimum, or most negative, expected DC
voltage from the transducer.
A voltage reading outside this range
constitutes a transducer fault, which is
indicated with the tachometer LED blinking red
and the TachFault input tag.
For information about the LEDs, see page 87.
For information about the input tags, see
page 91.
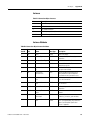
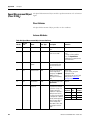
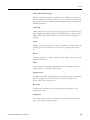
Inhibit Zero Pulse Tachometer Check to enable Inhibit Zero Pulse Tachometer Fault.
Fault
Clear to disable Inhibit Zero Pulse Tachometer Fault.
Controls whether a tachometer fault occurs if
no pulses are detected on the tachometer
signal.
Fault Delay
Enter a value between 1...64 seconds.
Enter the number of seconds that the module should
wait after the last valid pulse signal before it indicates
a tachometer fault.
Publication ICM-UM002F-EN-E - March 2013
69