1
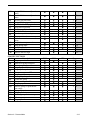
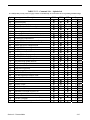
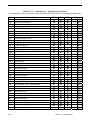
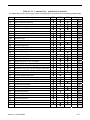
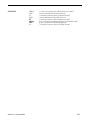
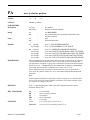
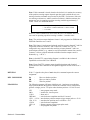
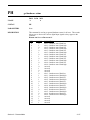
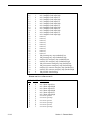
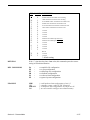
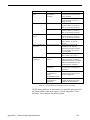
Command Index (Section 3)
Command Description
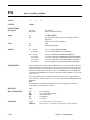
AB
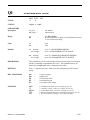
AC
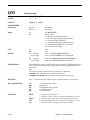
AE
AF
AG
AM
AP
AU
BA
BG
BK
BL
BM
BN
BO
BP
BQ
BR
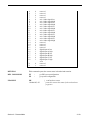
CL
CO
DB
DC
DD
DE
DF
DG
DH
DL
DO
DP
DV
EO
EP
ES
EX
FE
FP
FR
GR
HA
Preface
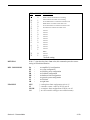
Page in section 3-
abort motion ...............................................................................................21
set acceleration...........................................................................................22
set e-stop deceleration................................................................................24
set acceleration feed-forward gain .............................................................26
set deceleration...........................................................................................27
set analog input mode ................................................................................29
abort program.............................................................................................30
set maximum acceleration and deceleration ..............................................31
set backlash compensation.........................................................................32
assign DIO bits to execute stored programs ..............................................33
assign DIO bits to inhibit motion...............................................................34
enable DIO bits to inhibit motion ..............................................................35
assign DIO bits to notify motion status......................................................36
enable DIO bits to notify motion status .....................................................37
set DIO port A, B, C direction ...................................................................38
assign DIO bits for jog mode .....................................................................40
enable DIO bits for jog mode.....................................................................41
set serial communication speed .................................................................42
set closed loop update interval...................................................................43
set linear compensation..............................................................................44
set position deadband.................................................................................45
setup data acquisition.................................................................................46
get data acquisition done status..................................................................50
enable/disable data acquisition ..................................................................51
get data acquisition sample count ..............................................................52
get acquisition data ....................................................................................53
define home................................................................................................54
define label.................................................................................................55
set dac offset ..............................................................................................56
read desired position ..................................................................................57
read desired velocity ..................................................................................58
automatic execution on power on ..............................................................59
enter program mode ...................................................................................60
define event action command string ..........................................................61
execute a program ......................................................................................63
set maximum following error threshold.....................................................64
set position display resolution....................................................................65
set encoder full-step resolution ..................................................................66
set master-slave reduction ratio .................................................................67
set group acceleration ................................................................................68
xi