1
ET
FUNCTION:
Electronic cam table
DESCRIPTION:
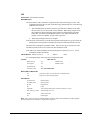
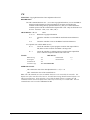
The ET command sets the ECAM table entries for the slave axes.. The values of the master
axes are not required. The slave entry (n) is the position of the slave axes when the
master is at the point (m ∗ i) + o, where i is the interval and o is the offset as determined
by the EP command.
ARGUMENTS: ET[m] = n,n,n,n,n,n,n,n
where
m is an integer in the range between 0 and 256.
n is an integer in the range between -2,147,438,648, and 2,147,438,647.
n=?
Returns the slave position for the specified point
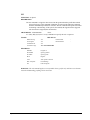
The value n can be left out of the command if the index count has been set using the
command, EC. In this mode, each ET command will automatically increment the index
count by 1.
USAGE:
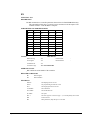
DEFAULTS:
While Moving
Yes
Default Value
In a Program
Yes
Default Format
Command Line
Yes
Controller Usage
ALL CONTROLLERS
RELATED COMMANDS:
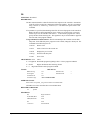
"EA"
Choose ECAM master
"EB "
Enable ECAM
"EC "
Set ECAM table index
"EG "
Engage ECAM
1
1
1
"EM "
Specify ECAM cycle
"EP"
Specify ECAM table intervals & staring point
"EQ "
Disengage ECAM
1
1
1
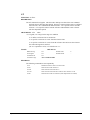
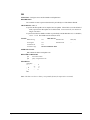
EXAMPLES:
ET[0]=0,,0
Specifies the position of the slave axes A and C to be synchronized with
the starting point of the master.
ET[1]=1200,,400
Specifies the position of the slave axes A and C to be synchronized with
the second point of the master
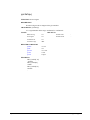
EC0
Set the table index value to 0, the first element in the table
ET 0,,0
Specifies the position of the slave axes A and C to be synchronized with
the starting point of the master.
ET 1200,,400
Specifies the position of the slave axes A and C to be synchronized with
the second point of the master
Optima/Econo DMC 2xxx Command Reference
ET ● 96