1
Problem Description
1. Set up and present a progress plan for your thesis work so that the due date can be met.
2. Review state-of-the-art integrated navigation systems for marine applications with respect to
criteria such as
performance and price.
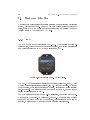
3. Acquire commercial-off-the-shelf GPS and IMU units (e.g., u-blox and MicroStrain products)
and co-locate these
units in a suitable container.
4. Develop sensor fusion algorithms for integration of GPS and IMU signals. Verify and validate
your design by
numerical simulations in Matlab/Simulink.
5. Verify and validate your design by full-scale experiments with a USV.
Assignment given: 14. January 2008
Supervisor: Morten Breivik, ITK