1
9 Motion-Control-Mode 3
Trajectory Control Mode
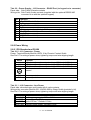
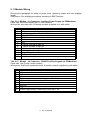
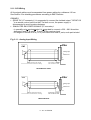
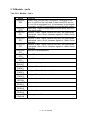
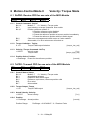
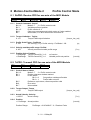
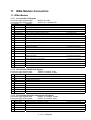
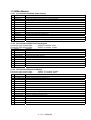
9.1 RxPDO: Receive PDO for one axis of the MCD-Module
Byte 1
Byte 2
Byte 3,4
Byte 5..8
Control
TrqLim
Velocity
Position
9.1.1
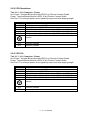
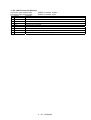
Control Command: Control
Bit 0..2
Mode 0..7
3 = Trajectory control mode
Bit 3
Micro interpolation enable
Bit 4,5
Position reference mode 0..3
0: Position reference cycle disabled
1: Position reference cycle enable
2: Preset the reference position at current position immediately
3: Preset the reference position whit limit switch signal
Bit 6
Clear error messages and switch motor on if axis enabled.
Bit 7
Axis enable, if no error exist motor will switch on.
9.1.2
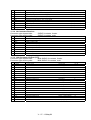
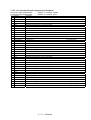
Torque Limitation : TrqLim
0..127
Torque PWM output limitation
9.1.3
9.1.4
[torque_low_res]
Velocity Limitation: Velocity
0..32767
Reference position set :
Set velocity limit
+/-32767
Reference position not set : Set velocity and direction
[1/min]
[1/min]
Position Value: Position
+/-PosRange Reference position set :
Set position for trajectory
[counts]
+/-PosRange Reference position not set : Preset for the reference position [counts]
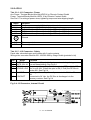
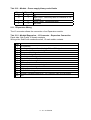
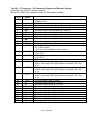
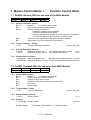
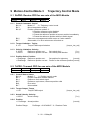
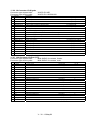
9.2 TxPDO: Transmit PDO for one axis of the MCD Module
Byte 1
Byte 2
Byte 3,4
Byte 5..8
Status
Torque
Velocity
Position
9.2.1
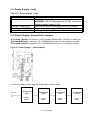
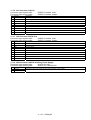
Control Status: Status
Bit 0..2
Mode 0..7
1 = Position control mode
Bit 3
Position tolerance window reached
Bit 4
Reference limit switch signal
Bit 5
Reference cycle done, reference position valid
Bit 6
Error exist
Bit 7
Axis enabled
9.2.2
Torque Output: Torque
+/-127
Torque PWM output
9.2.3
9.2.4
[torque_low_res]
Actual Velocity: Velocity
+/-32767
Actuel velocity
[1/min]
Position
+/- PosRange Actual position
[counts]
Position Range:
PosRange = 2147483647 * 2 / Resolver Pools
V - 22 – 13/May/02