1
Native Command Reference
MF
Motor OFF
Shuts off the motor current.
On DC motor versions this command turns the servo loop off; the motor no longer
holds its position actively and may be moved freely. The MF command is used to
prevent unwanted movement (servo dither) or to allow for manual positioning of
the unit. The motor position is still monitored in the MF status and may be queried
(e.g. by the TP command).
Be careful when using this command on stepper motor versions because the
controller may lose track of the motor position.
Examples:
Sets motor servo-control to OFF
MFCR
See also : MN (Motor ON)
Servo control can be enabled again anytime by MN.
MN
Motor ON
Sets the motor current back to the hold value. On DC motor versions,
automatically sets the target to the current position and reenables servo control, so
jerk-free activation of the servo loop is possible.
Note: stepper motor versions may have lost track of the position if they were in the
MF state.
Examples:
MN
Sets motor servo-control to ON
See also : MF (Motor OFF)
MRn
Move Relative
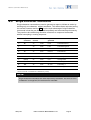
Initiates a move of relative distance of n counts/steps from the current target
position. n may be either a positive or negative number, and is added algebraically
to the current target to obtain the new target. The resulting absolute target position
must be between + and -1,073,741,823.
Motion is counted in encoder counts (DC motor versions) or (micro)steps (stepper
versions).
Examples:
www.pi.ws
Native Commands MS176E Release 1.0.1
Page 31