1
System philosophy
2.7.1
Profile generator
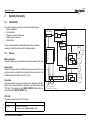
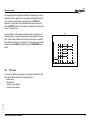
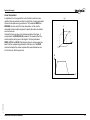
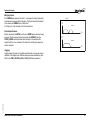
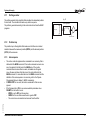
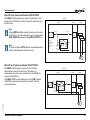
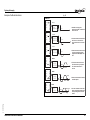
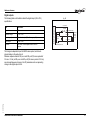
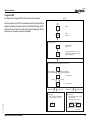
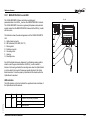
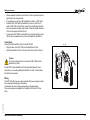
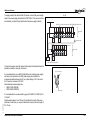
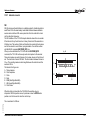
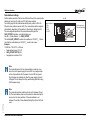
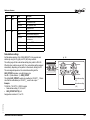
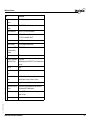
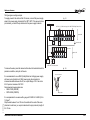
The profile generator is the algorithm that calculates the demanded position
for each axis. The calculation is made every motion sequence.
The profile is generated according to the motion instructions from the BASIC
programs.
fig. 27
Basic Program
.........
.........
MOVE(1000)
.........
.........
Profile generator
Demand Position
2.7.2
Position loop
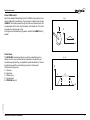
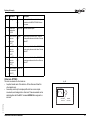
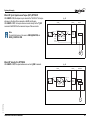
The position loop is the algorithm that makes sure that there is a minimal
deviation between the measured position (MPOS) and the demand position
(DPOS) of the same axis.
2.7.3
•
•
•
Axis sequence
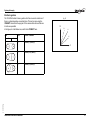
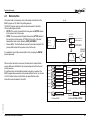
The motion controller applies motion commands to an axis array that is
defined with the BASE command. If the motion command concerns one
axis, it is applied to the first axis in the BASE array. If the motion
command concerns more than one axis, and makes an orthogonal
move, the axes are taken from the array in the order defined by the
BASE command. For more information on the BASE command and the
definition of the axis sequence in an axis array, refer to the Trajexia
Programming Manual, chapter 3 (BASIC commands).
If SERVO=OFF for one axis, the motion commands for that axis are
ignored.
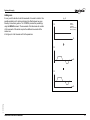
If the Following Error (FE) in one axis exceeds the parameter value
FELIMIT, the next action occurs:
- WDOG is set to OFF and all axes stop.
- SERVO for the axis that causes the error goes to OFF.
- The current move is cancelled and removed from the buffer.
Revision 2.0
HARDWARE REFERENCE MANUAL
37