1
4 Parameter Settings and Functions
Brake Output to
Servo OFF
trol and Torque Control
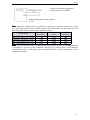
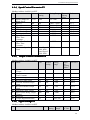
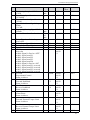
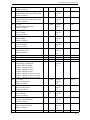
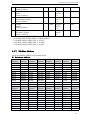
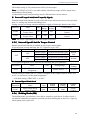
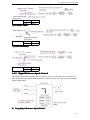
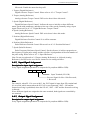
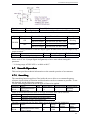
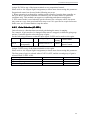
This parameter is used to set the output time from the brake control signal /BK until the
servo OFF operation (servomotor output stop).
With the standard setting, the servo is turned OFF when the /BK signal (brake operation)
is active. The equipment may move slightly due to gravity depending on equipment
configuration and brake characteristics. If this happens, use this parameter to delay servo
OFF timing.
This setting sets the brake ON timing when the servomotor is stopped.
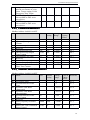
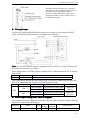
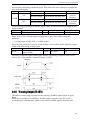
� Brake Output Timing (When Motor Is Rotating)
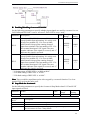
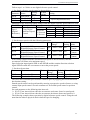
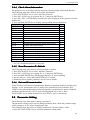
Set the following parameters to adjust brake ON timing so the holding brake is applied
when the servo driver stops a rotating motor.
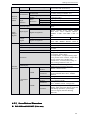
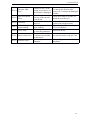
Setting Default
Parameter
Name
Unit
Control Mode
Range Setting
P5-07
Brake Output
rpm 0~5000
100
Position Control, Speed
Speed Limit
Control and Torque Control
P5-08
Brake Output Time 1ms 10~1000
500
Position Control, Speed
Limit
Control and Torque Control
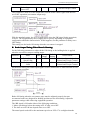
Set the brake timing used when input signal /S-ON is turned OFF or when an alarm occurs
during motor operation.
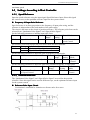
Brake ON timing when the servomotor stops must be adjusted properly because
servomotor brakes are designed for holding position not for decelerating. Adjust the
parameter settings while observing equipment operation.
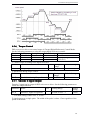
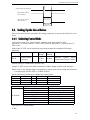
The /BK signal is ON under either of the following conditions:
1. Motor speed drops below the setting at P5-07 after servo OFF.
2. The time set at P5-08 has elapsed since servo OFF.
The actual speed used will be the maximum speed even if P5-07 is set higher than the
30