1
Motion Control with PTO and PWM Chapter 7
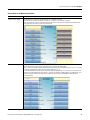
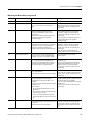
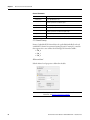
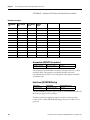
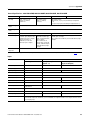
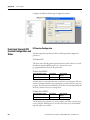
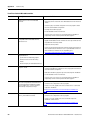
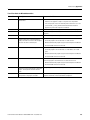
Motor and Load Parameters
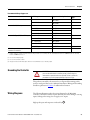
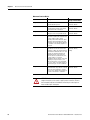
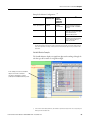
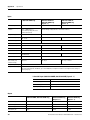
Parameter
Description and Values
User-defined unit
Defines user unit scaling that matches your mechanical system values.
These units shall be carried forward into all command and monitor axis in
user unit values throughout programming, configuration and monitoring
functions.
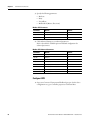
Position
Select from any of the following options:
– mm
– cm
– inches
– revs
– custom unit (ASCII format of up to 7 characters long)
Time
Read only. Predefined in seconds.
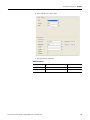
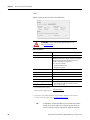
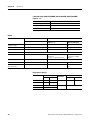
Motor revolution
Defines pulse per revolution and travel per revolution values.
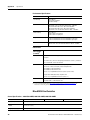
Pulse per revolution(1)
Defines the number of pulses needed to obtain one revolution of the
drive motor.
Range: 0.0001…8388607
Default: 200.0
Travel per revolution(1) Travel per revolution defines the distance, either linear or rotational, that
the load moves per revolution of the motor.
Range: 0.0001…8388607.
Default:1.0 user unit.
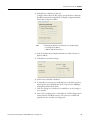
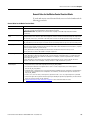
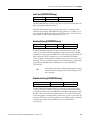
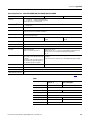
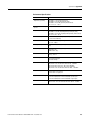
Direction
(1)
Defines polarity, mode, and change of delay time values.
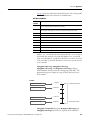
Polarity
Direction polarity determines whether the direction signal received by
the controller as a discrete input should be interpreted on the input as
received by the motion controller, (that is, the non-inverted case), or
whether the signal should be inverted prior to interpretation by the
motion control logic.
Set as Inverted or Non-inverted (default).
Mode
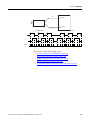
Set as Bi-directional (default), Positive (clockwise), or Negative
(counter-clockwise) direction.
Change delay time
Configure from 0…100 ms.
Default value is 10 ms.
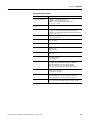
The parameter is set as REAL (float) value in Connected Components Workbench. To learn more about
conversions and rounding of REAL values, see Real Data Resolution on page 97.
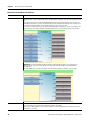
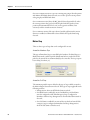
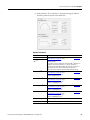
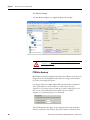
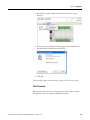
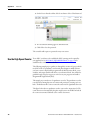
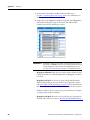
A red border on an input field indicates that an invalid value has been
entered. Scroll over the field to see tooltip message that will let you
know the valid value range for the parameter. Supply the valid value.
TIP
ATTENTION: Modifying Motor Revolution parameters may cause
axis runaway.
Rockwell Automation Publication 2080-UM002F-EN-E - December 2013
93