1
A Appendix
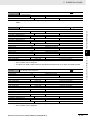
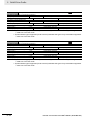
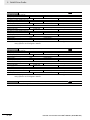
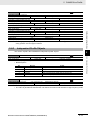
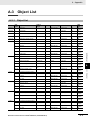
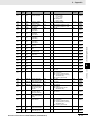
Index
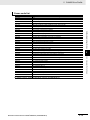
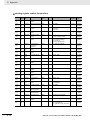
Subindex
Register
No.
Function name
Monitor and setting items
Data
resolution
PDO
map
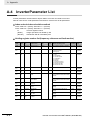
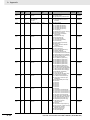
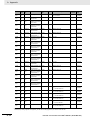
3016
hex
48
hex
161B
hex
Speed Deviation Error
Detection Level
P027
RW
0 to 12000
0.01 [Hz]
Possible
(TxPDO)
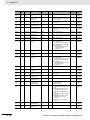
3016
hex
4C
hex
161F
hex
Acceleration/
Deceleration Time
Input Type
P031
RW
00: Digital Operator
03: Do not set.
−
Possible
(TxPDO)
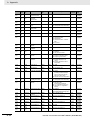
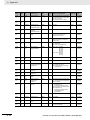
3016
hex
4E
hex
1621 hex
Torque Reference
Input Selection
P033
RW
00: Terminal FV
01: Terminal FI
03: Digital Operator
06: Do not set.
−
Possible
(TxPDO)
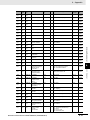
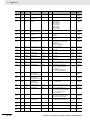
3016
hex
4F
hex
1622 hex
Torque Reference
Setting
P034
RW
0 to 200
1 [%]
Possible
3016
hex
51
hex
1624 hex
Torque Bias Mode
P036
RW
00: Disabled
01: Digital Operator
05: Do not set.
−
Possible
(TxPDO)
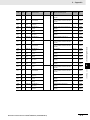
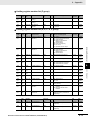
3016
hex
52
hex
1625 hex
Torque Bias Value
P037
RW
−200 to +200
1 [%]
Possible
3016
hex
53
hex
1626 hex
Torque Bias Polarity
Selection
P038
RW
00: As per sign
01: Depends on the RUN direction
−
Possible
(TxPDO)
3016
hex
55
hex
1628 hex
Speed Limit Value in
Torque Control
(Forward)
P039
RW
0 to 12000
0.01 [Hz]
Possible
(TxPDO)
3016
hex
57
hex
162A
hex
Speed Limit Value in
Torque Control (Reverse)
P040
RW
0 to 12000
0.01 [Hz]
Possible
(TxPDO)
3016
hex
58
hex
162B
hex
Speed/Torque Control
Switching Time
P041
RW
0 to 1000
1 [ms]
Possible
(TxPDO)
3016
hex
66
hex
1639 hex
Pulse Train Frequency
Scale
P055
RW
10 to 320 *Input frequency at
maximum frequency
0.1 [kHz]
Possible
(TxPDO)
3016
hex
67
hex
163A
hex
Pulse Train Frequency
Filter Time Constant
P056
RW
1 to 200
0.01 [s]
Possible
(TxPDO)
3016
hex
68
hex
163B
hex
Pulse Train Bias
Amount
P057
RW
-100 to +100
1 [%]
Possible
(TxPDO)
3016
hex
69
hex
163C
hex
Pulse Train Limit
P058
RW
0 to 100
1 [%]
Possible
(TxPDO)
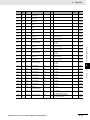
4016
hex
6B
hex
163E
hex
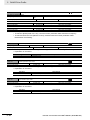
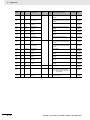
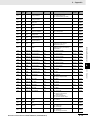
Multi-step Position
Command 0
P060
RW
Position range setting (reverse) to
position range setting (forward)
(Displays MSB 4 digits including "−")
1
Possible
4016
hex
6D
hex
1640 hex
Multi-step Position
Command 1
P061
R/W
Position range setting (reverse) to
position range setting (forward)
(Displays MSB 4 digits including "−")
1
Possible
4016
hex
6F
hex
1642 hex
Multi-step Position
Command 2
P062
RW
Position range setting (reverse) to
position range setting (forward)
(Displays MSB 4 digits including "−")
1
Possible
4016
hex
71
hex
1644 hex
Multi-step Position
Command 3
P063
RW
Position range setting (reverse) to
position range setting (forward)
(Displays MSB 4 digits including "−")
1
Possible
4016
hex
73
hex
1646 hex
Multi-step Position
Command 4
P064
RW
Position range setting (reverse) to
position range setting (forward)
(Displays MSB 4 digits including "−")
1
Possible
4016
hex
75
hex
1648 hex
Multi-step Position
Command 5
P065
RW
Position range setting (reverse) to
position range v (forward) (Displays
MSB 4 digits including "−")
1
Possible
4016
hex
77
hex
164A
hex
Multi-step Position
Command 6
P066
RW
Position range setting (reverse) to
position range setting (forward)
(Displays MSB 4 digits including "−")
1
Possible
4016
hex
79
hex
164C
hex
Multi-step Position
Command 7
P067
RW
Position range setting (reverse) to
position range setting (forward)
(Displays MSB 4 digits including "−")
1
Possible
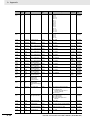
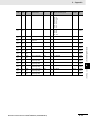
3016
hex
7B
hex
164E
hex
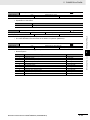
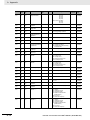
Zero Return Mode
P068
RW
00: Zero return mode 1
01: Zero return mode 2
−
Possible
3016
hex
7C
hex
164F
hex
Zero Return Direction
Selection
P069
RW
00: Forward
01: Reverse
−
Possible
3016
hex
7D
hex
1650 hex
Zero Return Mode 1
Frequency
P070
RW
0 to 1000
0.01 [Hz]
Possible
3016
hex
7E
hex
1651 hex
Zero Return Mode 2
Frequency
P071
RW
0 to 4000
0.01 [Hz]
Possible
4016
hex
7F
hex
1652 hex
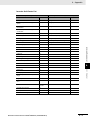
Position Range setting
(Forward side)
P072
RW
0 to 268435455
1
Possible
4016
hex
81
hex
1654 hex
Position Range setting
(Reverse side)
P073
RW
−268435455 to 0
1
Possible
EtherCAT Communication Unit USER’S MANUAL (3G3AX-MX2-ECT)
A - 29
A
A-3-1 Object List
R/W
A-4 InverterParameter List
Parameter
No.