1
PREPARATION AND SYSTEM CONFIGURATION
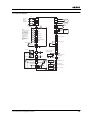
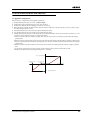
2.3 Connection diagram
Breaker, MCCB
or GFI
Power source,
3-phase or
1-phase, per
inverter model
R
U (T1)
S
V (T2)
(L1 )
(L2 )
Motor
W (T3)
T
N (L3 )
PD/+1
Intelligent inputs,
7 terminals
DC reactor
(optional)
24V
+-
P24
P/+
Forward
NOTE:
For the wiring of intelligent
I/O and analog inputs,
be sure to use twisted
pair / shielded cable.
Attach the shielded wire
for each signal to its
respective common
terminal at the inverter
end only.
Input impedance of
each intelligent input is
4.7 kΩ
1
Up
RB
2
Down
N/-
Brake
resistor
(optional)
Braking
unit
(optional)
3/GS1 GS1 input
11/EDM
4/GS2 GS2 input
12
5/PTC Quick speed
6
Motor contactor (KM1)
L
Inspection speed
7/EB Reset
AL1
PLC
AL2
Brake contactor (KA1)
Thermistor
Short bar
(Source type)
L
AL0
GND for logic inputs
L
P24
Freq. Meter
Termination resistor (200 Ω)
(Change by slide switch)
EO
SP
L
Volt. Meter
RS485
transceiver
AM
transceiver
Analog reference
0~10VDC
4~20mA
H
O
OI
10 VDC
Not used
Not used
Apprx.
10 Ω
+
-
GND for analog signals
Low Performance Lift Application Software
SN
RS485
transceiver
EA
L
Serial communication port
(RS485/ModBus)
L
L
Apprx.100 Ω
L
Pulse train input
24 VDC 32 kHz max.
CM2
L
L
RJ45 port
(Optional operator port)
L
USB
transceiver
USB (mini-B) port
(PC communication port)
L
Option port
controller
Option port connector
L
15