1
Getting started
39
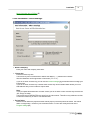
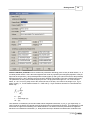
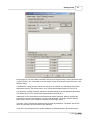
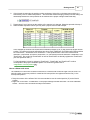
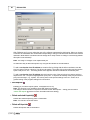
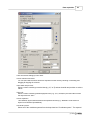
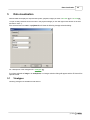
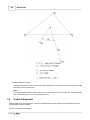
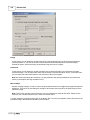
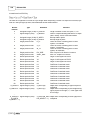
Internal calibration parameters can be divided into parameters describing (more or less) an ideal camera, i.e., a
so-called pinhole camera. This is the focal length and the center of projection (the orthogonal projection of the pinhole onto the chip surface). Two potentially different focal lengths (fx and fy) are used to account for the potentially
different pixel size in x and y direction and to account for different focal length's of the lens (cylindrical lens error).
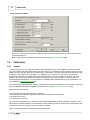
The parameters fx and fy are normalized by the pixel size. The physical focal length is fx * dx. In the example
above, fx * dx is 18.3 mm, pretty close to the nominal 20 mm of the lens. The center of the image is (Cx, Cy) in
pixels. Usually, i.e., for low distortion lenses Cx ~ Nx/2 and Cy ~ Ny/2. Deviations account for a decentered lens
and/or chip.
fx......[pix]
f........focal length [m]
dx.....[m]
Lens distortion is modelled by at least two radial and two tangential coefficients, k1, k2, p1, p2, respectively. In
case k3 and k4 are both 0, the camera model is identical to the one described in OpenCV. The parameters k3 and
k4 account for higher-order modelling of the radial distortion. The details on how the parameters are applied to
transform from undistorted coordinates (i.e., ideal pinhole camera) to distorted coordinates are contained in the
(c) 2005