1
Introduction to Control Functions
For further details on each function, see chapter 1, “Explanation of Functions” in the
CX2000 User’s Manual (IM 04L31A01-01E) provided on the accompanying CD-ROM.
Control Types
Control Mode
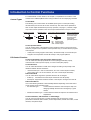
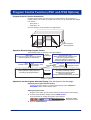
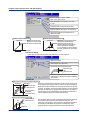
The following four control modes are available (three types of control plus analog
retransmission) and can be set for each control loop. The mode can be specified for
each control output terminal block (two loops per block, see page 7). However, single
loop control can be specified on the control output terminal block for loops 5 and 6.
Single-loop control
SP
PID
OUT
Cascade control
PV1
PV
SP
Loop control with PV switching
PV2
PID
PV1 PV2
SP
PID
OUT
PID
OUT
PV: Process value
SP: Target setpoint
OUT: Control output
Analog retransmission
Output comes from
the control output
channels per the
results of the
specified equation.
Control Operation Mode
You can specify either of the following control operation modes for each control loop.
However, program control operation can be specified only on models with the program
control option.
• Fixed-point control (program control OFF): Set the SP locally or use remote input
• Program control operation: Set the SP locally or use program patterns
PID Control Function
Control Computation Types and Control Output Format
You can select from time proportional PID control (voltage pulse/relay output),
continuous PID control (current output), or On/Off control (relay output).
Control Direction
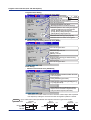
You can select the direction in which OUT changes according to the polarity of the
deviation between the SP and the PV.
• Reverse action (PV > SP: OUT decreases, PV < SP: control output increases)
• Direct action (PV > SP: OUT increases, PV < SP: control output decreases)
PID Control Mode
You can select the change in the operation when the SP is changed.
• Follow-up: Controlled so that the output reaches the new SP quickly
• Fixed-point: Suppresses sensitive reaction of the output to change to the new SP
PID Control Method
One of the following methods is automatically selected depending on the PID control
mode and the control operation mode.
• PV derivative type:
Control method in which the control output is kept from
changing radically when the SP is changed by a great
amount
• Deviation derivative type: Control method in which fast response to follow the SP is
emphasized
Control Parameter (“PID Parameter” in the Settings)
You can set up to eight groups of control parameter sets for each loop. Control
parameters include SP, PID constant, control output limiter, manual reset value, control
direction, and preset output.
4
IM 04L31A01-02E