1
E100/E1001-CO/DN
Series E100/E1001-CO/DN
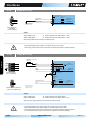
E100-CO
E200-CO
E400-CO
E1001-CO
E2001-CO
E4001-CO
E100-DN
E200-DN
E400-DN
E1001-DN
E2001-DN
E4001-DN
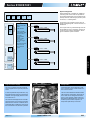
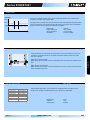
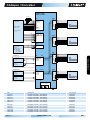
E100, E200, E400-CO/DN
CO
Mot A
Motor A
Sys 1
System Interface 1
Mot B
Motor B
Sys 2
System Interface 2
Mot C
Motor C
Com
COM Interface
Mot D
Motor D
PWR
Motor/Logic Supply
Absolute & Relative
Positioning Commands
RS/CAN Bus Address
Travel Along Time Curves
Trigger Mode: Two Point
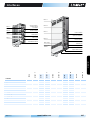
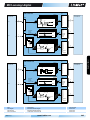
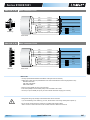
E1001, E2001, E4001-CO/DN
E4001-
CO
1 Ph1+
red
2 Ph1-
pink
3 Ph2+
Mot A
Motor A
Motor A
Trigger Mode: Curves
1
blue
4 Ph2-
grey
5 +5VD
C
6 AGND
white
inner shield
7 SIN
yellow
8 COS
10
green
9 TEMP
10 SHIE
black
LD outer
shield
Internal Command Table
Analog Position Target
Motor B
1
Mot B
Motor B
10
State
56
34
789A
S1
789A
56
34
(hex)
ID LOW
F012
S2
PWR Motor
Motor Power Supply
Regeneration Resistor
Sys 1
Mot D
Motor D
5 GND
9 CAN
H
10
4
8 CAN
3 RS23 L
2 Rx
7
2 RS23
2 Tx
6
1
Sys 2
System Interface 2
PGND
PWR+
+
RR
Motor Suppl
y
72 (24..8
0) VDC
Logic Suppl
y
24 (22..5
0) VDC
PE
+24VDC
DGND
COM / CONFIG
Option:
Customer-Specific Functions
Sys 1
System Interface 1
Motor D
1
Sys 2
10
MOT SUPPLY
E100/E1001-CO/DN
H
F012
ID HIG
CDE
B
Mot C
Motor C
CDE
B
Master-Slave Synchronization
Motor C
1
Com
COM Interface
PWR Logic
Logic Supply
Option Master Encoder
Option Master Encoder I/O’s
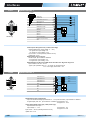
CANopen
DeviceNet
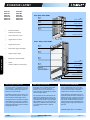
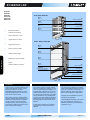
LinMot CO controllers, with integrated CANopen interface, support the CiA DS301
communication profile.
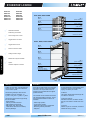
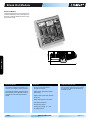
Series DN controllers feature an integrated
DeviceNet interface. With the DeviceNet
interface, even complicated motion sequences can be realized with the highest
possible flexibility.
The following CANopen resources are
available on the CO controllers: 1-5
T_PDO, 1-5 R_PDO 1 T_SDO, 1 R_SDO
The following protocols are supported by
the CO controllers:
- Node Guarding
- PDO acyclic with inhibit time
- SDO Upload and Download
- NMT (Start, Stop, Enter PreOp,
Reset Node, Reset Communication)
- Boot-Up Message
240
The controller can be actuated and monitored via the DeviceNet connection. The following expanded fieldbus functions are
available:
- Direct target position
- Invoke motion profiles
- Read and write access to parameters
- Monitoring internal parameters
- Diagnosis
www.LinMot.com
"Explicit Messaging" The DeviceNet Servo
Controllers support one "Explicit Messaging" connection per master.
"Polled IO"
The master initiates data interchange with
a "Polled IO" command.
"Change of State IO"
With this connection, the data is transferred only if the states or values have changed.
"Cyclic IO"
With the "Cyclic IO" connection, the data is
transferred strictly cyclically.
Edition 15
subject to change