1
3
3.1
Model Predictive Control Overview
Introduction
Model Predictive Control (MPC) is an Advanced Process Control (APC) technology which is used
commonly in the Chemical Engineering and Process Engineering fields. MPC allows control of all plants
from Single Input Single Output (SISO) through to Multiple Input Multiple Output (MIMO) and nonsquare systems (different numbers of inputs and outputs). However its real advantage is the ability to
explicitly handle constraints, such that they are included when calculating the optimal control input(s)
to the plant. Among other attractive features, this has enabled MPC to be the preferred APC technology
for a number of years, and continues to this day.
Several variants of the MPC algorithm exist, including the original Dynamic Matrix Control (DMC),
Predicted Functional Control (PFC), Generalized Predictive Control (GPC) as well as nonlinear and
linear MPC. However all retain a common functionality; a model of the system is used to predict the
future output of the plant so that they controller can predict dead-time, constraint violations, future
setpoints and plant dynamics when calculating the next control move. This enables robust control which
has proved its use in industry and academia for over 20 years.
3.2
Linear MPC Algorithm
The MPC algorithm used within the jMPC Toolbox is a linear implementation, where a linear state space
model is used for the system prediction. This enables the controller to formulate the control problem as a
Quadratic Program (QP), which when setup correctly results in a convex QP, ensuring an optimal input
(global minimum). The fundamental algorithm characteristic is the system prediction and subsequent
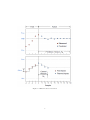
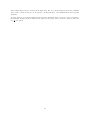
control move optimization, shown below:
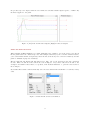
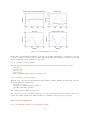
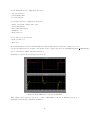
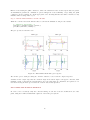
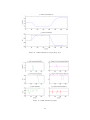
Viewable in Figure 2 is the standard MPC prediction plot, where the top plot shows the predicted plant
output for the prediction horizon, and the bottom plot shows the planned control inputs for the control
horizon. The linear model which is used to build the controller is used for the plant prediction, viewable
as the blue dots. With a good model of your system this prediction can be quite accurate, enabling
the control moves to optimally move the system to the setpoint. Also shown in the above plots are the
constraints available to MPC including maximum and minimum inputs and outputs, as well maximum
rate of change of the input.
3.3
The jMPC Controller
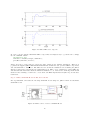
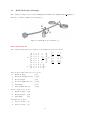
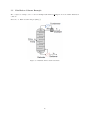
Referring to Figure 1 shows how the jMPC controller is included in a system. The jMPC controller uses
the current setpoint (setp) and measured disturbance (mdist), together with the current plant output
measurement (yp ) to calculate the optimal control input (u). For simulation purposes you can also
add an unmeasured disturbance (umdist) and measurement noise (noise) to the plant to test how the
controller responds. For analysis purposes you can also read the model states (xm ) and the model output
(ym ), which can be compared to the plant states (xp ) and plant output (yp ).
When running a simulation the plant is represented by either a jSS (State Space) linear plant, or a
collection of nonlinear (or linear but this is unusual as it should be converted to state space) Ordinary Differential Equations (ODEs) in a jNL plant. This enables you to perform linear and nonlinear
simulations using the same jMPC controller, and just changing the plant object.
6