1
User's Manual
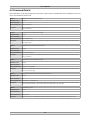
Function:
Read tare orientation(Quaternion)
Command Value:
128 (0x80)
Return Data Bytes:
16
Return Data Format: Quaternion(float x4)
Description:
Reads the tare orientation as a quaternion.
Function:
Read tare orientation(Rotation Matrix)
Command Value:
129 (0x81)
Return Data Bytes:
36
Return Data Format: Rotation Matrix(float x9)
Description:
Reads the tare orientation as a rotation matrix.
Function:
Read rho data(Accelerometer)
Command Value:
130 (0x82)
Return Data Bytes:
9
Return Data Format: Rho mode(byte, 1 for confidence, 0 for static), min/static rho(float), (max rho(float))
Description:
Reads the rho mode and rho data for the accelerometer.
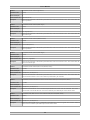
Function:
Read rho data(Compass)
Command Value:
131 (0x83)
Return Data Bytes:
9
Return Data Format: Rho mode(byte, 1 for confidence, 0 for static), min/static rho(float), (max rho(float))
Description:
Reads the rho mode and rho data for the compass.
Function:
Read current update rate
Command Value:
132 (0x84)
Return Data Bytes:
4
Return Data Format: Update rate in microseconds(int)
Description:
Reads the amount of time the last frame took.
Function:
Read compass reference vector
Command Value:
133 (0x85)
Return Data Bytes:
12
Return Data Format: Vector(float x3)
Description:
Reads the single mode compass reference vector.
Function:
Read accelerometer reference vector
Command Value:
134 (0x86)
Return Data Bytes:
12
Return Data Format: Vector(float x3)
Description:
Reads the single mode accelerometer reference vector.
Function:
Read reference vector mode
Command Value:
135 (0x87)
Return Data Bytes:
1
Return Data Format: Mode(byte, 0 for single static, 1 for single auto, 2 for single auto continuous, 3 for multi)
Description:
Reads the current reference vector mode. See command 105 for details.
37