1
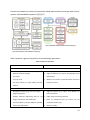
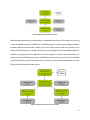
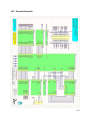
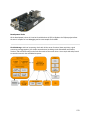
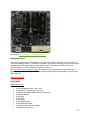
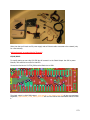
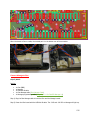
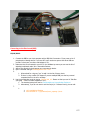
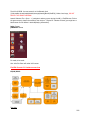
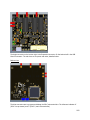
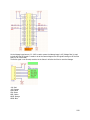
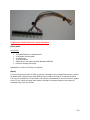
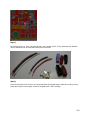
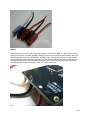
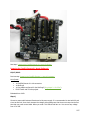
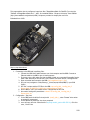
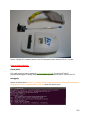
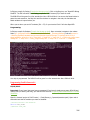
Power Execute (15-28V) Program your Execute board with the latest firmware: Programming FlexSEA-Execute 0.1 (please not that if you just followed Preparing the FlexSEA-Execute 0.1 board (Software) you don't have to do this step again) You can now stream sensor values: Read multiple sensors from Linux (Execute) The next step is to Add and control an output device (Execute) from Linux At this point controlling a motor is a simple task, but it requires a new wiring harness. Introduction to FlexSEA Abstract: FlexSEA aims to enable fast prototyping of multi-axis and multi-joint active prostheses by developing a new modular electronics system. This system provides the required hardware and software for precise motion control, data acquisition, and networking. Scalability is obtained by the use of a fast industrial communication protocol between the modules, and by a standardization of the peripherals’ interfaces: it is possible to add functionalities to the system by simply plugging additional cards. Hardware and software encapsulation is used to provide high-performance, real-time control of the actuators while keeping the high-level algorithmic development and prototyping simple, fast, and easy. Simplest full-stack system: FlexSEA-Plan: Embedded computer for high-level computing. Can run a full Linux operating system and execute Python or Matlab scripts. Can connect to the network through WiFi or Bluetooth. Currently a BeagleBone Black (COTS). 169