1
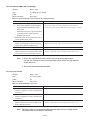
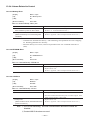
TL
: Torque Limit Rate
Format
: TL data
Data
: 0 ~ 100 [%]
Shipping set
: 100
Default
:0
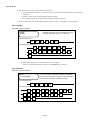
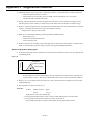
¡ Sets the torque limit.
¡ The Motor torque will be reduced to a percentage (%) of the maximum torque immediately after “TL” is
input and the Motor torque is controlled not to exceed the limit.
¡ “TS” or “?TL” reads the current setting.
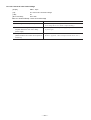
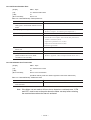
TP
: Tell Position
Format
: TP data/RP
Data
: 2, 5
Shipping set
: None
Default
: Not omissible
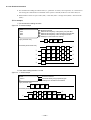
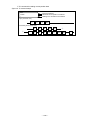
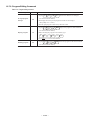
¡ “TP” command reads the current position of the Motor in the position scale set by PS parameter.
¡ If /RP is executed with an /RP option, reading is repeated automatically.
¡ If only “TP data” is executed, the display shows the position at the moment.
¡ To terminate automatic reading, press the BS key.
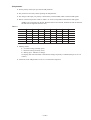
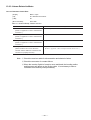
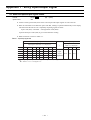
¡ TP2/RP: in the units of pulse
YS, JS1, JS2, RS : 614400 pulses/revolution
SS
: 491250 pulses/revolution
AS, BS, JS0
: 409600 pulses/revolution
¡ TP5/RP : in the units of 0.01°
36000/revolution
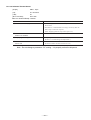
TR
: Tell RDC Position Data
Format
: TR/RP
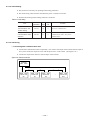
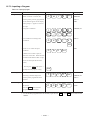
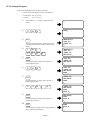
¡ TR reads data of RDC position data.
¡ Data is between 0 and 4095.
¡ If TR command is executed with /RP option, reading is repeated automatically.
¡ To terminate automatic reading, press the BS key.
¡ “TR” command reads out the status at the moment.
– 11-29 –