1
5.12
Design Overview
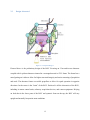
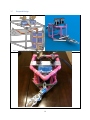
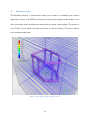
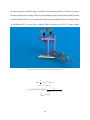
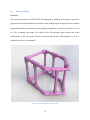
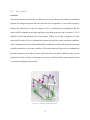
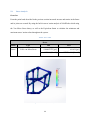
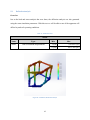
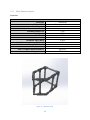
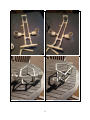
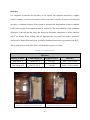
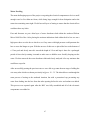
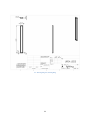
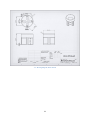
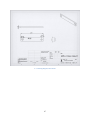
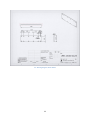
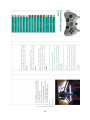
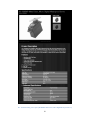
The structural design of our MATE ROV consists of a flow-through hollow frame design which
incorporates aluminum mounting bars which the 2-DOF manipulator arm as well as the Pelican
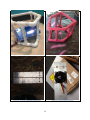
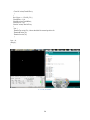
Diving Box are affixed to. The structure has been modeled as a solid body made out of PVC to
avoid contact errors within our simulation program, although the pipes are still hollow. By fixing
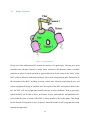
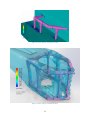
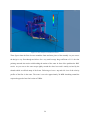
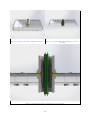
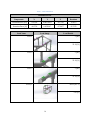
the opposite end as to where the force is applied to, we were able to properly indicate the
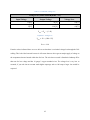
reflected force upon the structure. First by simulating the mounting bar that the motors will be
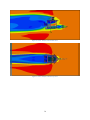
mounted on and then applying a point load upon the point of contact of 5 lb-f a good
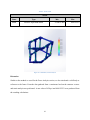
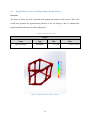
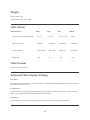
approximation of the systems operating conditions can be determined. An overall factor of safety
of 3 for the system was observed indicating that our design was a success and can withstand
more than what our motors produce.
52