1
System Interconnection
J7
J2
J6
J3
2.00
.75
J8
J1
4.40
2.50
J4
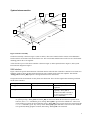
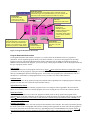
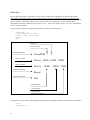
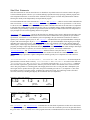
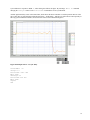
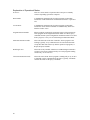
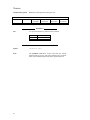
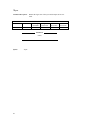
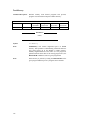
Figure 3: Bracket Assembly
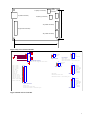
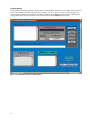
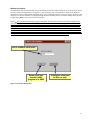
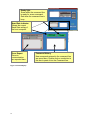
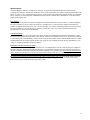
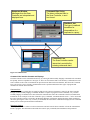
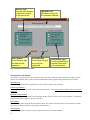
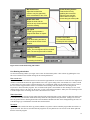
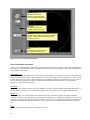
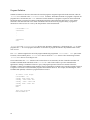
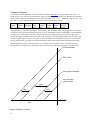
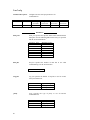
The bracket assembly is shown in Figure 3 (units are inches). The Scan Controller bracket consists of an aluminum Lbracket with two #8 clearance holes located on the riser. The circuit board standoff nearest J4 also serves as the heatsink
mounting point for the 5-volt regulator.
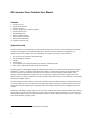
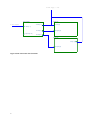
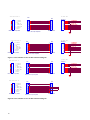
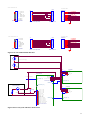
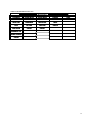
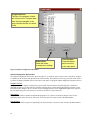
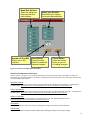
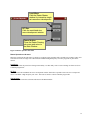
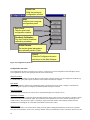
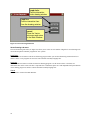
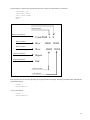
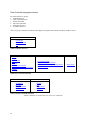
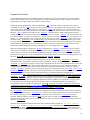
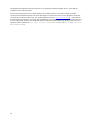
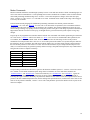
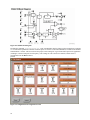
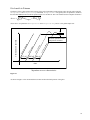
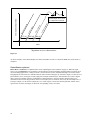
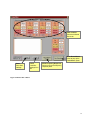
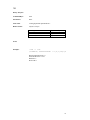
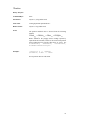
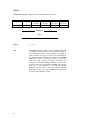
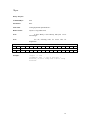
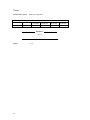
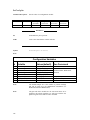
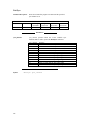
A sketch of the top view of the Scan Controller is shown in Figure 4, with its pinout shown in Figure 5, and a system
interconnection diagram in Figure 6.
SAX Interface
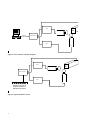
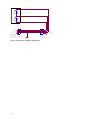
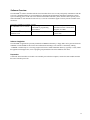
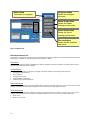
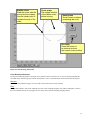
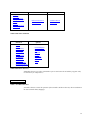
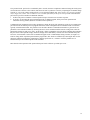
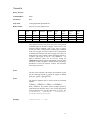
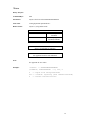
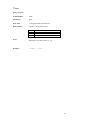
Figure 7 shows the specific interconnection of the SAX interface when the Scan Controller is attached to two SAX servo
amplifiers. Figure 8 shows the interconnection between Scan Controller and a single SAX amplifier. Note that the
~Temp_OK and ~Servo_Rdy inputs have been grounded out for the unused axis.
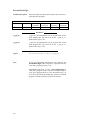
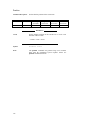
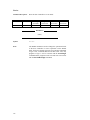
The operation of the SAX interlock circuitry bears some discussion. There are three signals interconnecting each SAX
and the Scan Controller:
~Servo_Rdy
~Temp_OK
SAX output
SAX thermal controller output
~Servo_Enb
SAX input
indicates functioning servo
indicates temperature in
regulation
required for servo operation
(typically, ~Servo_Enb is
asserted, and within a second or
so ~Servo_Rdy goes true if the
servo is functional)
The interlock system is as follows:
On system powerup, ~Servo_Enb and ~Servo_Rdy are unasserted. When the user desires to operate one or
both axes, the Enable command is given, causing ~Servo_Enb to go low for the enabled axes. After a wait
period of about 2 seconds, the Scan Controller expects ~Servo_Rdy to be asserted, and to stay asserted until the
Disable command is given. Any activity on the ~Servo_Rdy signal until then is cause for an error condition
to be generated, halting program execution, and causing ~Servo_Enb to be unasserted.
5