1
What is the WPI Robotics Library
C++
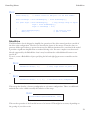
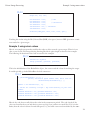
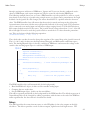
The following C program demonstrates driving the robot for 2 seconds forward during the Autonomous period and driving with arcade-style joystick steering during the
Operator Control period. Notice that constants define the port numbers used in the
program. This is a good practice and should be used for C and C++ programs.
#include “WPILib.h”
#include “SimpleCRobot.h”
static const UINT32 LEFT_MOTOR_PORT = 1;
static const UINT32 RIGHT_MOTOR_PORT = 2;
static const UINT32 JOYSTICK_PORT = 1;
void Initialize(void)
{
CreateRobotDrive(LEFT_MOTOR_PORT, RIGHT_MOTOR_PORT);
SetWatchdogExpiration(0.1);
}
void
{
}
Autonomous(void)
SetWatchdogEnabled(false);
Drive(0.5, 0.0);
Wait(2.0);
Drive(0.0, 0.0);
void OperatorControl(void)
{
SetWatchdogEnabled(true);
while (IsOperatorControl())
{
WatchdogFeed();
ArcadeDrive(JOYSTICK_PORT);
}
}
START_ROBOT_CLASS(SimpleCRobot);
6