1
1-82
Process Control Instructions (ALM, D2SD, D3SD, DEDT, FGEN, LDLG, PIDE, POSP, RMPS, SCL, SRTP, TOT)
Arithmetic Status Flags: Arithmetic status flags are set for the PositionPercent output.
Fault Conditions: none
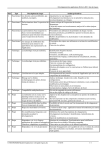
Execution:
Condition:
Function Block Action:
Structured Text Action:
prescan
OpenOut and CloseOut are cleared.
OpenTime = 0
CloseTime = 0.
OpenOut and CloseOut are cleared.
OpenTime = 0
CloseTime = 0.
instruction first scan
The internal cycle timer is reset.
The internal cycle timer is reset.
The instruction calculates OpenTime and Close Time. The instruction calculates OpenTime and Close Time.
instruction first run
No action taken.
No action taken.
EnableIn is cleared
EnableOut is cleared, the instruction does nothing,
and the outputs are not updated.
na
EnableIn is set
The instruction executes.
EnableOut is set.
EnableIn is always set.
The instruction executes.
postscan
No action taken.
No action taken.
Example: In this example, the POSP instruction opens or closes a motor-operated valve
based on the CVEU output of the PIDE instruction. The actual valve position
is wired into the Position input and optional limit switches, which show if the
valve is fully opened or closed, are wired into the OpenedFB and ClosedFB
inputs. The OpenOut and CloseOut outputs are wired to the open and close
contacts on the motor-operated valve.
Structured Text
FlowController.PV := WaterFlowRate;
PIDE(FlowController);
FlowValve.SP := FlowController.CVEU;
FlowValve.Position := FlowValvePosition;
FlowValve.OpenedFB := FlowValveOpened;
FlowValve.ClosedFB := FlowValveClosed;
POSP(FlowValve);
OpenFlowValveContact := FlowValve.OpenOut;
CloseFlowValveContact := FlowValve.CloseOut;
Publication 1756-RM006D-EN-P - May 2005