1
Advanced Settings
Transition Speed
(Only appears in the Settings menu when “Planing” or
“Waterjet” is selected as the “Boat type”.
To make this adjustment you need speed input from either SOG
or Log.
Planing boats may often have very different steering
characteristics before and after planing. The same may apply for
water jet driven boats at low and high speed. AP50 offers the
possibility of using the Auto-Work mode values for Rudder and
Counter Rudder at low speed. By setting the Transition Speed
to a value different from the default = 0, the Work parameters
for Rudder, Counter Rudder and RateOfTurn/Radius will
automatically be used for speed below the set value.
Note !
Other special work functions (thruster control, disabling of
special alarms etc.) do not apply without the Work mode being
manually selected.
For a planing boat it is recommended to set the Transition
Speed to the value that represents the speed where the hull
begins to plane. For a water jet boat it should be set to a value
that represents the speed where it begins giving good response
from the main steering.
Range: OFF - 40
Default: OFF
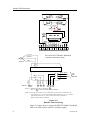
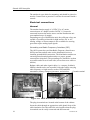
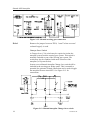
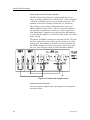
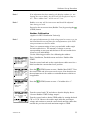
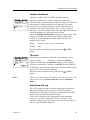
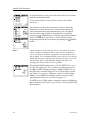
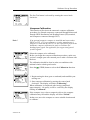
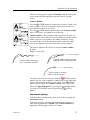
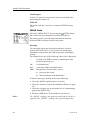
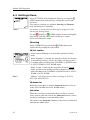
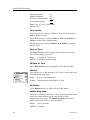
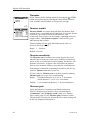
Nav Gain
SETTINGS
Nav gain
3.5
Minimum rudder
0.0°
Turn mode
ROT
RateOfTurn
240°/min
W RateOfTurn
033°/min
Added stop time
0s
Init NAV
Firm
Turn Gain
1.0
W Turn Gain
10.0
Rate sensitivity
15
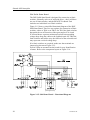
The Nav Gain determines how many degrees the autopilot must
change the vessel’s heading in order to bring the vessel back on
track, using the Cross Track Error and the vessel’s speed (refer
also to the Operator Manual/User Set-Up Menu/Nav Mode).
Range:
0.5 to 7.
Default:
Depends on the boat length.
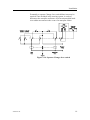
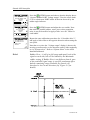
Minimum rudder
Some vessels may have a tendency of not responding to small
rudder deflection around “used” midship position because of a
possible rudder deadband or whirls/disturbance of the waterstream passing the rudder.
By setting the Minimum Rudder to a certain value, the autopilot
will add this value to any given rudder command.
The amount of rudder command is determined by adding the
minimum rudder value and the rudder deadband value to the pfactor value.
20222410 / B
87