1
Drive functions
7.3 Function modules
7.3.6.6
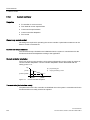
Travel to fixed stop
Description
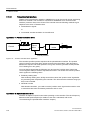
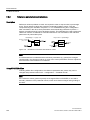
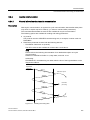
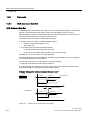
The "Travel to fixed stop" function can be used, for example, to traverse sleeves to a fixed
stop against the workpiece with a predefined torque. In this way, the workpiece can be
securely clamped. The clamping torque can be parameterized in the traversing task (p2622).
An adjustable monitoring window for travek to fixed stop prevents the drive from traveling
beyond the window if the fixed stop should break away.
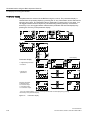
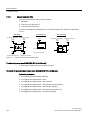
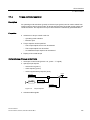
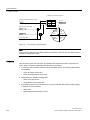
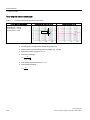
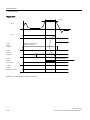
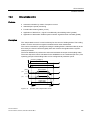
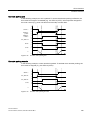
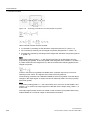
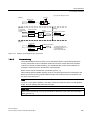
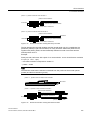
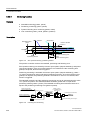
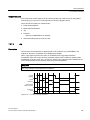
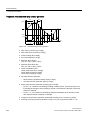
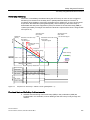
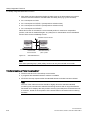
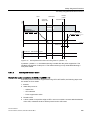
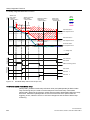
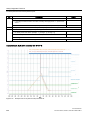
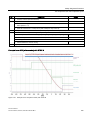
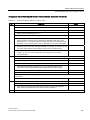
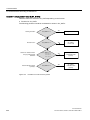
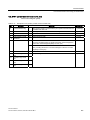
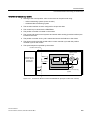
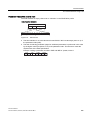
In positioning mode, travel to fixed stop is started when a traversing block is processed with
the FIXED STOP command. In this traversing block, in addition to the specification of the
dynamic parameterized position, speed, acceleration override and deceleration override, the
required clamping torque can be specified as task parameter p2622. From the start position
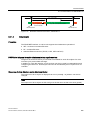
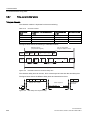
onwards, the target position is approached with the parameterized speed. The fixed stop (the
workpiece) must be between the start position and the braking point of the axis; that is, the
target position is placed inside the workpiece. The preset torque limit is effective from the
start, i.e. travel to fixed stop also occurs with a reduced torque. The preset acceleration and
deceleration overrides and the current speed override are also effective. Dynamic following
error monitoring (p2546) in the position controller is not effective when traveling to the fixed
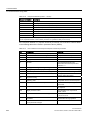
stop. As long as the drive travels to the fixed stop or is in fixed stop, the "Travel to fixed stop
active" status bit r2683.14 is active.
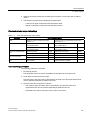
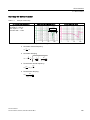
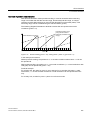
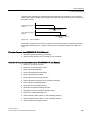
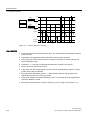
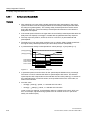
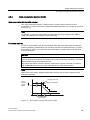
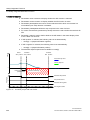
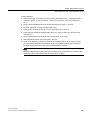
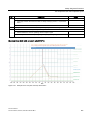
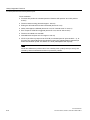
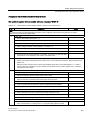
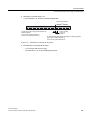
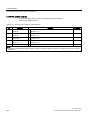
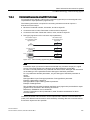
Fixed stop is reached
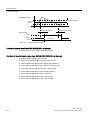
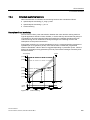
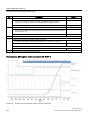
As soon as the axis comes into contact with the mechanical fixed stop, the closedloop
control in the drive raises the torque so that the axis can move on. The torque increases up
to the value specified in the task and then remains constant. Depending on the binector input
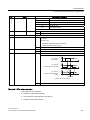
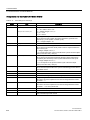
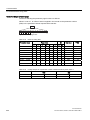
p2637 (fixed stop reached), the "fixed stop reached" status bit r2683.12 is set if:
● the following error exceeds the value set in parameter p2634 (fixed stop: maximum
following error) (p2637 = r2526.4)
● external status via the signal at binector input p2637 (fixed stop reached), if this p2637 ≠
r2526.4)
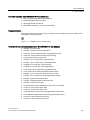
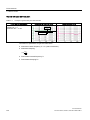
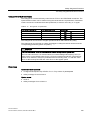
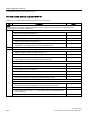
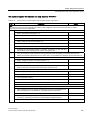
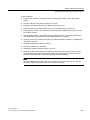
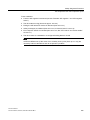
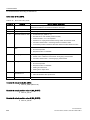
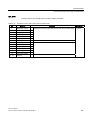
In travel to fixed stop, the clamping torque or clamping force in the traversing block is
configured via the task parameter. This is specified in units of 0.01 Nm (rotary motor). The
function module is coupled to the torque limit of the basic system via the connector output
r2686[0] (torque limit upper) or r2686[1] (torque limit lower), which are connected to the
connector input p1528 (torque limit upper scaling) or p1529 (torque limit lower scaling). The
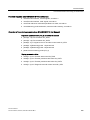
connector outputs r2686[0] (torque limit upper) and r2686[1] (torque limit lower) are set to
100% when fixed stop is not active. During active fixed stop, r2686[0] (torque limit upper) or
r2686[1] (torque limit lower) are evaluated as a percentage of p1522/p1523 in such a way
that the specified clamping torque or clamping force is limited.
Function Manual
Function Manual, 06/2012, 6SL3097-4AB10-0BP4
259