1
Preparation for commissioning
1.5 Rules for wiring with DRIVE-CLiQ
19.At a "SERVO" or "VECTOR" drive object, the number of connected encoders must be
equal to the number of parameterized encoder data sets (p0140). A maximum of three
encoders are permissible per drive object.
Exception:
– For a maximum quantity structure of 6 axes in servo control with a controller cycle of
125 μs and one Line Module, a maximum of 9 encoders can be connected.
– For 5 axes in servo control with a controller cycle of 125 μs, a maximum of 15
encoders can be connected.
20.A maximum of up to 24 drive objects can be connected.
21.A maximum of 16 Terminal Modules can be connected to the CU320-2.
Note: If a TM15 Base, TM31, TM54F or a TM41 is connected, it is necessary to reduce
the number of connected standard axes.
22.Cycle times with TM31
A maximum of 3 Terminal Modules 31 (TM31) can be connected for a 2 ms time slice.
Note
A Double Motor Module, one DMC20, one DME20, one TM54F and one CUA32 each
correspond to two DRIVE-CLiQ participants. This also applies to Double Motor Modules,
at which just one drive is configured.
23.The communication basic clock cycles (p0115[0] and p4099) of all components that are
connected to a DRIVE-CLiQ line must be divisible by one another with an integer result.
– The smallest communication basic clock cycle is 125 µs.
– The exception are a maximum of 3 servo-controlled axes with 62.5 µs communication
basic clock cycle or a servo-controlled axis with 31.25 µs communication basic clock
cycle.
24.For current controller clock cycles Ti < 125 μs, the Motor Modules - also with the same
controller clock cycle - must be symmetrically connected to two DRIVE-CLiQ ports.
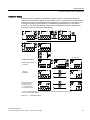
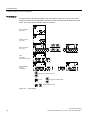
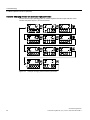
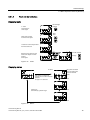
25.The fastest sampling time of a drive object in servo control mode is given as:
– Ti = 31.25 µs: Exactly 1 drive object in servo control
– Ti = 62.5 µs: Max. 3 drive objects in servo control
– Ti = 125 µs: Max. 6 drive objects in servo control
26.The fastest sampling time of a drive object in vector control mode is given as:
– Ti = 250 µs: Max. 3 drive objects in vector control
– Ti = 400 µs: Max. 5 drive objects in vector control
– Ti = 500 µs: Max. 6 drive objects in vector control
27.The fastest sampling time of a drive object in vector U/f vector control mode is given as:
– Ti = 500 µs: Max. 12 drive objects in U/f control mode
Commissioning Manual
Commissioning Manual, (IH1), 01/2011, 6SL3097-4AF00-0BP1
23