1
PLCopen
for efficiency in automation
•
•
•
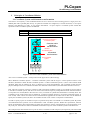
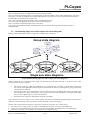
If a single axis MC_Home is issued the group is in state GroupMoving.
If a single axis MC_Stop is issued the group is in state GroupMoving.
If supported by the system, it is allowed to disable a single axis of the axis group without influencing the axes
group state. This can be useful to save energy or to apply a mechanical brake for a single axis not involved in the
on-going motion.
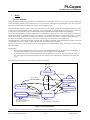
General rules for the interaction between a group and the single axis in it (for all 3 options above):
• If the group is commanded by a group moving command, all the single axes in the group are in the state
SynchronizedMotion
• If the group is in the state GroupStandby, the states of the single axes do not have to be all in StandStill
• If the group is in the state GroupErrorStop the state of the single axis is not affected
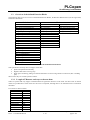
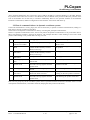
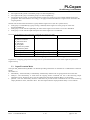
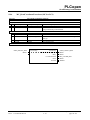
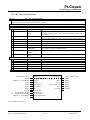
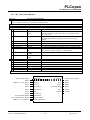
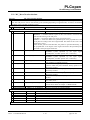
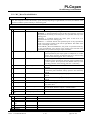
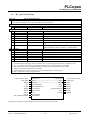
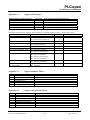
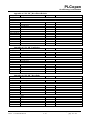
Overview of the influence of group motion commands on a single axis state:
Command
Group State
Axis state
MC_MoveLinearXxx
MC_MoveCircularXxx
MC_MoveDirectXxx
MC_MovePath
MC_GroupHalt
MC_TrackConveyorBelt
MC_TrackRotaryTable
MC_GroupStop
GroupMoving
SynchronizedMotion
GroupStopping / GroupStandby
SynchronizedMotion / StandStill
MC_GroupReset
GroupErrorStop / GroupStandby
Not relevant for Axis
MC_GroupHome
GroupHoming
SynchronizedMotion
Table 5: Overview of the influence of group motion commands on a single axis state
Explanation: A stopping group leaves the single axis in synchronized motion as none of the single axis performs a
single axis stop.
3.3
Input Execution Mode
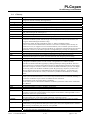
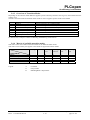
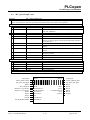
The input MC_EXECUTION_MODE is an ENUM providing information on the behavior of administrative function
blocks.
The modes are:
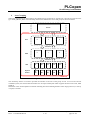
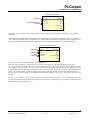
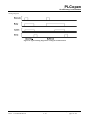
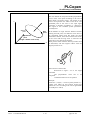
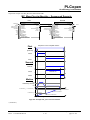
• Immediately - the functionality is immediately valid and may influence the on-going motion but not the state
• Delayed - The functionality is valid when the ongoing motion command sets one of the following output
parameters: Done, Aborted or Error. This also implies that the output parameter Busy is set to FALSE.
• Queued - The new functionality becomes valid when all previous motion commands sets one of the following
output parameters: Done, Aborted or Error. This also implies that the output parameter Busy is set to FALSE.
TC2 - Task Force Motion Control
Part 4 – Coordinated Motion
December 3, 2008
V 1.0
© PLCopen – 2007 - 2008
page 21/ 119