1
PLCopen
for efficiency in automation
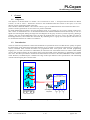
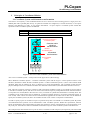
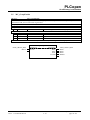
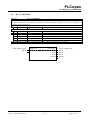
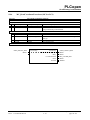
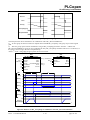
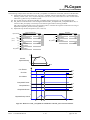
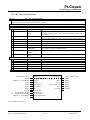
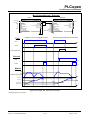
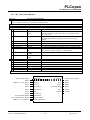
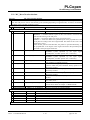
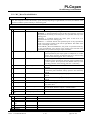
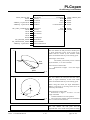
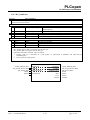
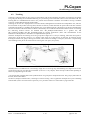
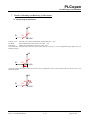
CircMode = RADIUS
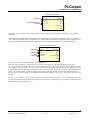
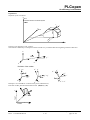
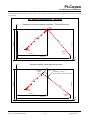
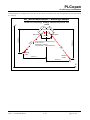
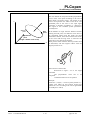
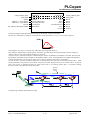
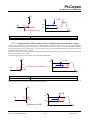
The user defines the end point and the perpendicular
vector of the circle plane according to the rule of
right thumb (see figure below). The length of the
vector corresponds to the radius of the circle. The
spearhead point of the vector is the input signal
'AuxPoint' in absolute coordinates, i.e. referring to
the origine of the coordinate system specified in
'CoordSystem'.
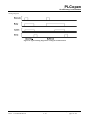
Y
Starting
point
End
point
Spearhead
point
(length = Radius of the circle)
X
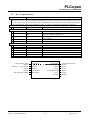
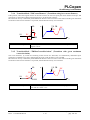
If the diameter is larger than the distance between
starting and end point, two different circles have to
be considered. When using this mode, the input
'PathChoice' defines, if the circle with the short sector
or the circle with the long sector to reach the end
point has to be cruised by the machine.
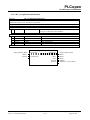
With positive radius value the shortest possible circle
is determined, and with negative radius value the
largest possible circle.
Inconvenience of this mode:
−
Restriction to angles < 2π in one single
command
−
The perpendicular vector has to be
computed.
−
Overdetermination of circle equation
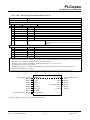
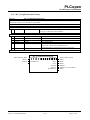
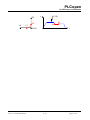
Example:
AuxPoint = (50,0,0) → Circle in plane parallel to yz plane with radius 50 and rotation around axis
parallel to x-axis according to the rule of right thumb
(CoordSystem = MCS)
TC2 - Task Force Motion Control
Part 4 – Coordinated Motion
December 3, 2008
V 1.0
© PLCopen – 2007 - 2008
page 66/ 119