1
RobotPy WPILib Documentation, Release master
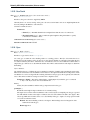
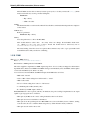
Parameters pov – which POV (default is 0)
Returns The angle of the POV in degrees, or -1 if the POV is not pressed.
GenericHID.getRawAxis(which)
Get the raw axis.
Parameters which – index of the axis
Returns the raw value of the selected axis
GenericHID.getRawButton(button)
Is the given button pressed?
Parameters button – which button number
Returns True if the button is pressed
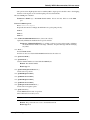
GenericHID.getThrottle()
Get the throttle.
Returns the throttle value
GenericHID.getTop(hand=None)
Is the top button pressed
Parameters hand – which hand (default right)
Returns True if the top button for the given hand is pressed
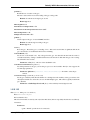
GenericHID.getTrigger(hand=None)
Is the trigger pressed
Parameters hand – which hand (default right)
Returns True if the trigger for the given hand is pressed
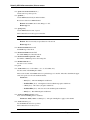
GenericHID.getTwist()
Get the twist value.
Returns the twist value
GenericHID.getX(hand=None)
Get the x position of HID.
Parameters hand – which hand, left or right (default right)
Returns the x position
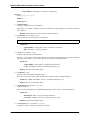
GenericHID.getY(hand=None)
Get the y position of the HID.
Parameters hand – which hand, left or right (default right)
Returns the y position
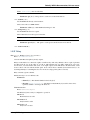
GenericHID.getZ(hand=None)
Get the z position of the HID.
Parameters hand – which hand, left or right (default right)
Returns the z position
126
Chapter 1. Contents