1
NDSU
Mechanical Systems Systems
ECE 461
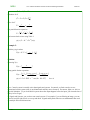
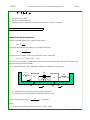
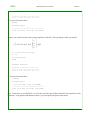
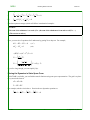
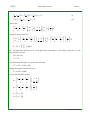
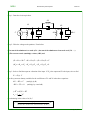
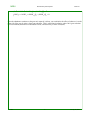
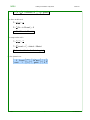
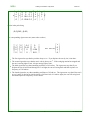
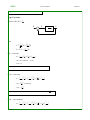
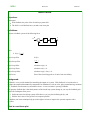
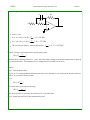
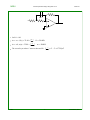
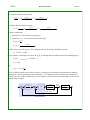
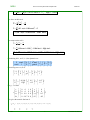
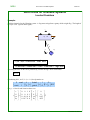
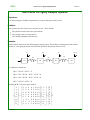
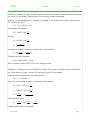
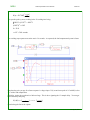
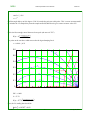
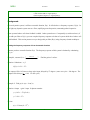
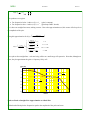
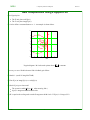
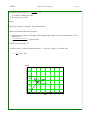
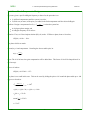
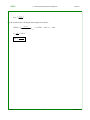
(J 1 s 2 + 0.04J 2 s 2 + 0.04K 2 )Q 1 − (0.04K 2 )Q ∗3 = T 1
(0.04J 3 s 2 + 0.04D 1 s + 0.04K 2 )Q ∗3 − (0.04K 2 )Q 1 = 0
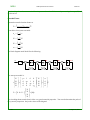
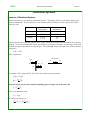
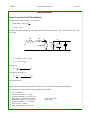
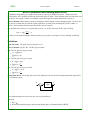
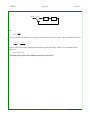
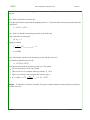
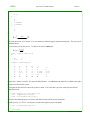
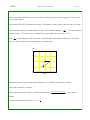
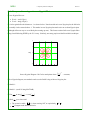
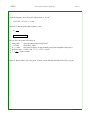
Since the admittance translates as the gear ratio squared, it allows you to minimize the effect of whatever is on the
other side of the gear by using a large gear reduction. This is often done in robotics, where 300:1 gear reduction
is not uncommon (the motor sees the outside world, scaled down by a factor of 90,000!)
JSG
5
rev July 16, 2009