1
4.4 Defuzzification
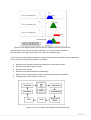
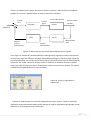
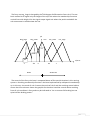
From the control advice we have to calculate a non-fuzzy numeric value for the control
variable as a numeric value.The resulting membership function is composed of the
superimposition of partial areas of triangles and trapezoids the position of the center of
gravity of the total area on the output signal axis is the non-fuzzy value investigated[7].We can
guess a mechanical system in which the three columns for the acceleration values that weight
is a function of their height.The columns are balanced on a consist in along the axis.Then we
can calculate the numeric control variable to find out the non-fuzzy value ;
∑
∑
.
=
. , .
,
, . ,
,
. ,
,
≈ −0,3 (Siemens user`s manual)
If we consider the this example we can realize that vehicle’s brake is executed with approx %30 .
28