1
Control Moment Gyroscope - ECP Model750
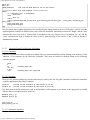
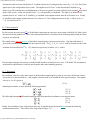
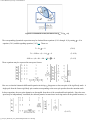
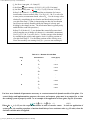
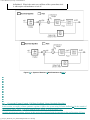
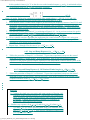
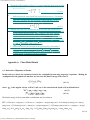
In this synthesis choose Q=C'C so that the error at the intended
outputs, q3 and q4, is minimized
subject
to the control effort cost R.
Choose a
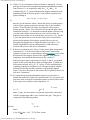
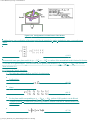
diagonal weighting[40]
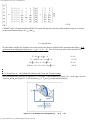
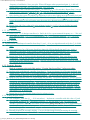
(6.7-5)
where r is scalar. Perform the synthesis for control effort
weight values: r = 100, 10, 1, 0.1, and 0.01. Calculate the closed loop poles for each
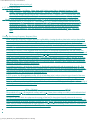
case as the eigenvalues of [A–BK]
2. From this data, select a control effort
weight to put the lowest pole frequency between 2 and 2.5 Hz and
the highest pole frequency
not greater than 5 Hz (absolute value if complex). Use one of the above
obtained K values if it meets this criteria, or
interpolate between the appropriate r
values and perform
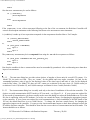
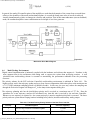
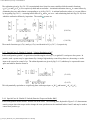
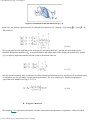
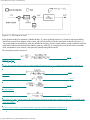
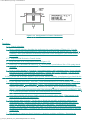
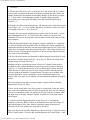
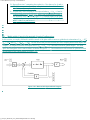
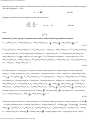
one last synthesis iteration. 3. Calculate the prefilter gain matrix Kpf by referring
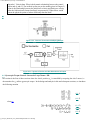
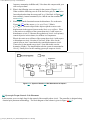
to Figure 6.8-1. As in previous sections, the goal is
to have the outputs Y = [q3(t) q4(t)]’ scaled equal
to the input R(t) = [r1(t) r2(t)]’.
4. Write a suitable real-time algorithm that
implements the control scheme of Figure 6.8-1 using your
results from Steps
1, 2 and 3. Use Ts = 0.00884 s. Have your instructor
or laboratory supervisor review
and approve your routine before proceeding.
5. Repeat Steps 1 through 4 for the case of {q2o = 30o, q3o = -30o}.
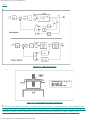
6.8.2 Step and Ramp Reponses @ q2o = 20o, q3o = -20o
6. Follow the procedure of Steps 9-13 of Section 6.7.2
(previous experiment) except use the control
algorithm of Steps 1-4 in this
section. Save all data
plots. How do the step and ramp tracking
responses of the present system compare with those of the independent
controller based system of the
previous section? How do their cross-coupling characteristics
compare?
6.8.3 Step and Ramp Reponses @ Off-Nominal Gimbal
Angles (q2o=30o, q3o=-30o)
7. Follow the procedure of Steps
9-13 of Section 6.7.2 (previous experiment) except use the control
algorithm of
Step 5 in this section. Save all data
plots. How do the responses of the
present system
compare with those of the {q2 = 20o, q3 = -20o} system?
Exercises
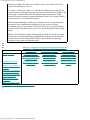
A. Compare the single step, step
series, and ramp response of Section 6.8.2
with those of the previous section (e.g. compare their step response rise
times, overshoot, and cross-coupling and their ramp response closeness
of
tracking. Compare the responses
of Section 6.8.3 with those of
Section 6.8.2 and of the previous section.
B. Simulate step
responses for q3* (q4*=0) and for q4* (q3*=0) where q3*=q3
-q3o and q4*=q4 –q4o for the present system using
your controller for the
case of {q2o = 30o, q3o = -30o}. How does the simulation compare with
your
experimental results? gyroscope_Model750_User_Manual.htm[9/28/2015 2:33:52 PM]