1
sensing because the sensor is stationary while the magnet rotates. Because the magnet itself is
not electrically powered, it has no wires to get tangled. The contact switches, however, are prone
to tangling. Thus the design employs the magnetic sensors to prevent unnecessary turning of the
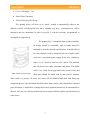
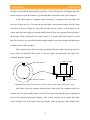
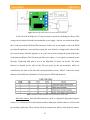
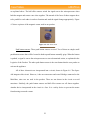
mechanism and will not allow the switches’ wires to tangle. The gripping assembly, shown in
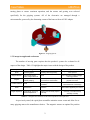
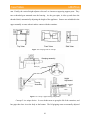
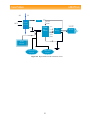
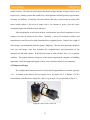
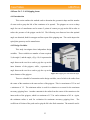
Figure 1.2, consists of a bracket with the embedded contact switch housing a gripping pad and
spring. One switch is used per assembly to avoid redundancy. This allows the product to sense
the presence of a container, but only for a given spring force. If the force required to grip the
container is less than the preset spring force, the microcontroller does not sense the presence of a
container and must continue opening the container. However, if it senses the container, the
microcontroller counts for a specific amount of time, and if it senses through the magnet sensor
that the container is still not opening, it reverses to prevent the motors from drawing too much
current, potentially destroying the product’s electronics.
Figure 1.2. Gripping assembly components
Driving these gripping assemblies are gears with a 6:1 ratio to transmit the desired
torque. The advantage to using gears is the positive contact between the two. Finally, the
gravity-dependent height adjustment of the appliance allows it to grasp the lid without resisting
vertical displacement while the container twists, causing the lid to rise off of the container. The
3