1
Issue 03/02
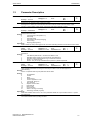
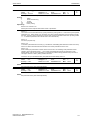
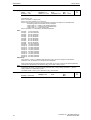
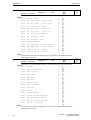
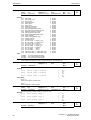
P2200[3]
Parameters
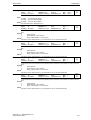
BI: Enable PID controller
CStat:
CUT
P-Group: TECH
Datatype: U32
Active: first confirm
Unit: QuickComm. No
Min:
Def:
Max:
0:0
0:0
4000:0
Level:
2
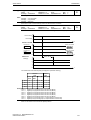
PID mode Allows user to enable/disable the PID controller. Setting to 1 enables the PID closed-loop
controller.
Index:
P2200[0] : 1st. Command data set (CDS)
P2200[1] : 2nd. Command data set (CDS)
P2200[2] : 3rd. Command data set (CDS)
Dependency:
Setting 1 automatically disables normal ramp times set in P1120 and P1121 and the normal frequency
setpoints.
Following an OFF1 or OFF3 command, however, the inverter frequency will ramp down to zero using the
ramp time set in P1121 (P1135 for OFF3).
Note:
The PID setpoint source is selected using P2253. The PID setpoint and the PID feedback signal are
interpreted as [%] values (not [Hz]). The output of the PID controller is displayed as [%] and then normalized
into [Hz] through P2000 (reference frequency) when PID is enabled.
In level 3, the PID controller source enable can also come from the digital inputs in settings 722.0 to 722.2
for DIN1 to DIN3 or from any other BiCo source.
Notice:
The minimum and maximum motor frequencies (P1080 and P1082) as well as the skip frequencies (P1091
to P1094) remain active on the inverter output. However, enabling skip frequencies with PID control can
produce instabilities.
Parameter List MICROMASTER 430
6SE6400-5AF00-0BP0
133