1
Chapter 7 Arm Movement
SetCPSpdMode (Library) [Version 1.8 or later]
Function
Keeps the TCP speed (Tool end speed in CP motion) constant or restores it to the default.
Syntax
SetCPSpdMode<SetValue>
Description
If you specify a CP motion involving the rotation of the robot hand, then the system will automatically decrease
the TCP speed according to the rotation angle by default. Setting 1 to <SetValue> may keep the TCP speed
constant as long as the rotation angle is less than the specified value.
Notes
If <SetValue> is set to 1, the rotation speed will vary depending upon the robot motion in order to keep the TCP
speed constant. If you specify such a motion that will exceed the rotation speed limit, then the system will issue
a warning message and run the robot while decreasing the TCP speed.
Example
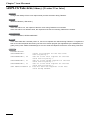
CALL SetCPSpdMode(0)
CALL SetCPSpdMode(1)
'Restore to the default.
'Set the TCP speed to "1."
7-24