1
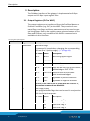
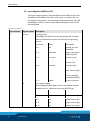
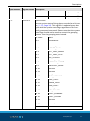
Commands
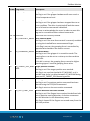
Grasping State
During finger movement, the grasping state is set to RELEASING.
When the end position is reached (or in case of an error), the
grasping state is set to IDLE.
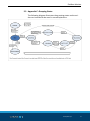
System State
Various transitions will occur. You should use the grasping state to
evaluate the current state of the grasping process, unless you have
very special requirements.
01.00|WSG |en
21