1
ATTENTION
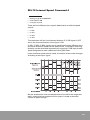
If inertia ratio is set, servo drive changes system gain (SEt-42)
and 5 basic gains according to inertia ratio. Therefore,
adjustment of the inertia ratio should be done carefully.
SEt-67 Speed Limit
•
Setting range: 1 to 5000 RPM
•
User Default: 5000
•
Changes while the servo is OFF
This parameter is the set value of internal speed limit. If this setting
exceeds the maximum motor speed, it is automatically limited to
maximum motor speed.
SEt-68 Maximum Torque Used
•
Setting range: 0 to 1000%
•
User Default: 500
•
Changes anytime
The highest torque value of the torques used up to now is stored to
this parameter. Even after the power is shut down, the value will
remain.
SEt-69 System Bandwidth
•
Setting range: 0 to 500
•
Factory Default: 60
•
Changes while the servo is OFF
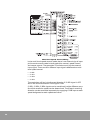
If auto tuning is executed or user changes the inertia ratio, system gain
and 5 basic gains changed after referring to the value of system
bandwidth.
Basic gain is categorized in five items that are essential for tuning.
•
Speed Loop Proportional Gain (Nms, SEt-02)
•
Speed Loop Proportional Gain (Nms2, SEt-03)
•
Position Loop Proportional Gain (rad/s, SEt-04)
•
Torque Command Filter (rad/s, SEt-06)
•
Speed Command Filter (rad/s, SEt-40)
173