1
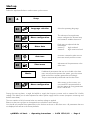
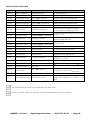
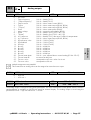
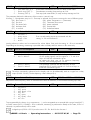
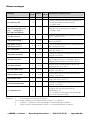
State
Relay picks up...
Ready
... if there is no trip and the drive is not running.
if the control voltage is applied with activated mains contactor control C6.00.
Run
... on accepted Start command or guided deceleration.
Trip
... on trip, until confirmed.
Ready and Run
... if a ready or run state exists.
Alarms
... during a programmed warning situation (see Appendix A).
Bus alarm
... while bus communication is interrupted.
Generator
operation
... if the motor is in generator state.
Line ON
... on switch-over to Line ON state with activated contactor control C6.00.
Local operation
... as long as the drive is in LOCAL mode.
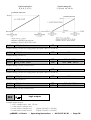
f(n)=fREF
... if the frequency act. value corresponds to the reference value (D4.08).
if speed control is activated, the actual speed is compared.
f>fLEVEL
... if f > "f-Level ON" D4.06, and drops off again when f < "f-Level OFF" D4.07.
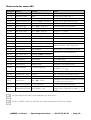
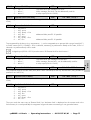
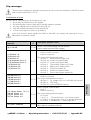
Output C1
... if conditions in comparator block C1 are met (F4.00 to F4.07).
Output C2
... if conditions in comparator block C2 are met (F4.08 to F4.15).
Output C3
... if conditions in comparator block C3 are met (F4.16 to F4.29).
Output C4
... if conditions in comparator block C4 are met (F4.30 to F4.43).
Output L5
... if conditions in logic module L5 are met (F4.44 to F4.49).
Output L6
... if conditions in logic module L6 are met (F4.50 to F4.55).
Thyristor-ON
... if charging of the DC link is completed.
BUS Control w. 11
... if the free bit 11 in the bus control word is 1.
BUS Control w.12
... if the free bit 12 in the bus control word is 1.
BUS Control w.13
... if the free bit 13 in the bus control word is 1.
BUS Control w.14
... if the free bit 14 in the bus control word is 1.
BUS Control w.15
... if the free bit 15 in the bus control word is 1.
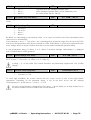
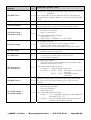
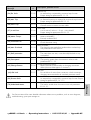
ON (+24V)
... as soon as control voltage is available (+24V interrogation voltage for digital inputs).
Manual operation
... if the drive is in manual mode (D1, D2).
2.Param.set active
... on switch-over to parameter set 2 using a digital input (B2.04).
Ext.T-limit. active
... if an external torque limitation is activated (E1.01).
PID active
... if the PID controller is active (C4.04).
PID enabled
... if the output of the PID controller is active (C4).
Trip inverted
... if there is no trip (= drive is ready for operation).
Limit I >
... if the current limitation is active *) or the heatsink temperature is too high.
Limit V >
... if the voltage limitation is active. *)
Limit Temp. >
... if the motor protection (thermal motor state) is active.
Limitations
... if one of the limitations above is active.
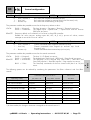
Alarm 1
... during a programmed warning situation (see Appendix A).
Alarm 2
... during a programmed warning situation (see Appendix A).
Motor heat. active
... if the function "Motor heating" is active.
*) The message for this limitation is currently not in function !
>pDRIVE< MX basic – Operating instructions – 8 074 157.01/01 – Page 59
D
In/Outputs
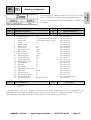
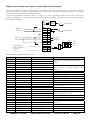
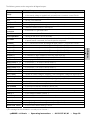
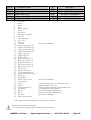
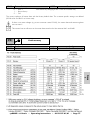
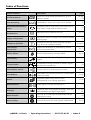
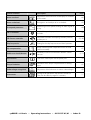
The following states can be assigned to all digital outputs: