1
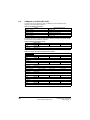
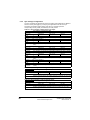
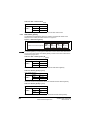
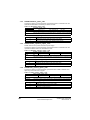
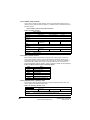
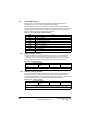
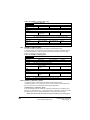
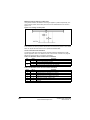
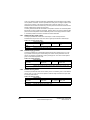
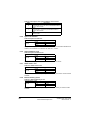
This read only object provides the actual value of the position feedback device. The
value is given in internal units.
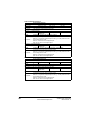
Table 7.28 Position_actual_value
Introduction
0x6064
Position_actual_value
Range: 0 to
0xFFFFFFFF
Access: RO
Size: signed 32
Safety
information
7.3.16 0x6064 Position_actual_value
Unit: N/A
N/A
Description:
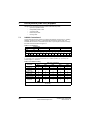
This read only object provides the actual value of the position feedback device.
The value is given in internal units.
Mechanical
installation
Default:
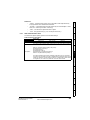
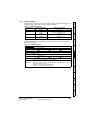
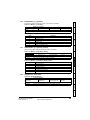
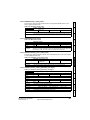
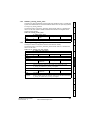
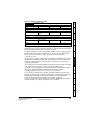
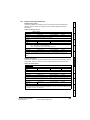
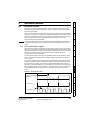
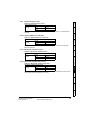
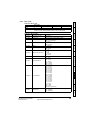
7.3.17 0x6080 Max motor speed
Description:
Max motor speed
Range: 0 to 0xFFFFFFFF Size: Unsigned 32
Unit: rpm
3000
This object indicates the configured maximum allowed speed for the motor in either
direction. It is used to protect the motor and changing the value of this object will
also change Pr 1.06. The value is given in rotations per minute (rpm).
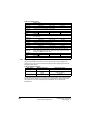
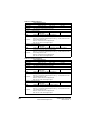
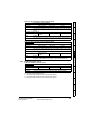
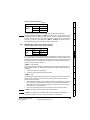
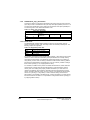
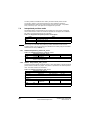
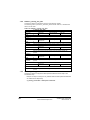
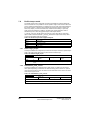
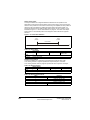
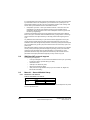
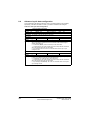
This read only object provides the actual value of the following error. The value is given
in user-defined position units.
0x60F4
Drive profile (DSP-402)
support
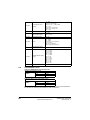
Table 7.30 Following_error actual_value
Following_error actual_value
Range: 0 to
0xFFFFFFFF
Access: RO
Size: signed 32
Unit: N/A
Default:
N/A
Description:
This read only object provides the actual value of the following error.
Advanced
features
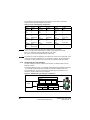
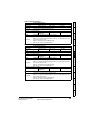
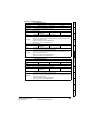
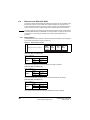
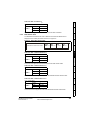
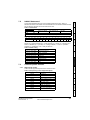
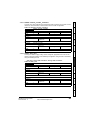
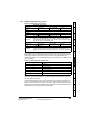
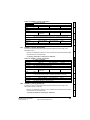
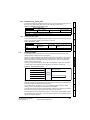
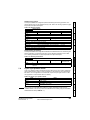
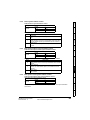
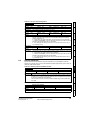
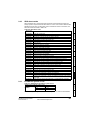
7.3.19 0x60FB Position_control_parameter_set object
Table 7.31 Position_control_parameter_set object
0x60FB
Position_control_parameter_set
Range: N/A
Size: Unsigned 8
Default:
2
Description:
The number of control loop parameters.
Diagnostics
Sub-index 0
Access: RO
Unit: N/A
Size: Unsigned 16
2500
Description:
The position controller proportional gain.
Unit: 0.01 rad/s/rad
Unit: 1 / 1000
Glossary of
terms
Range: 0 to 65535
Default:
Quick
reference
Sub-index 1
Access: RW
Sub-index 2
Access: RW
Range: 0 to 65535
Size: Unsigned 16
Default:
1000 (i.e. a gain of 1)
Description:
The position controller speed feed forward gain.
Protocols
7.3.18 0x60F4 Following_error_actual_value
Getting started
0x6080
Sub-index 0
Access: RW
Default:
Electrical
installation
Table 7.29 Max motor speed
Index
SM-EtherCAT User Guide
Issue Number: 5
www.controltechniques.com
47