1
GSK CNC Equipment Co., Ltd.
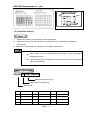
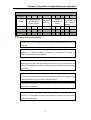
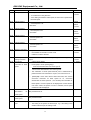
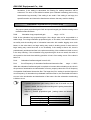
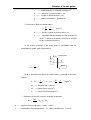
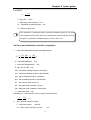
G:electronic gear ratio;
G=dividing numerator / dividing denominator
1
≤ G ≤ 50
50
Recommended range of G is:
N:motor rotating circles;
C:photoelectric encoder lines/rev, in this system C=2500
【Example 1】When input instruction pulse is 6000, and servo motor rotation is 1:
G=
N × C × 4 1 × 2500 × 4 5
=
=
P
6000
3
so parameter PA12 is set for 5 and PA 13 is set for 3.
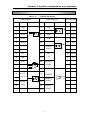
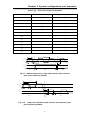
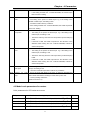
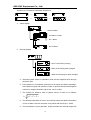
【Example 2】
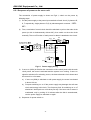
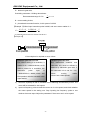
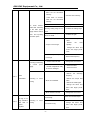
If the workpiece is required to move 10mm
Electronic gear ratio not used
Electronic gear ratio used
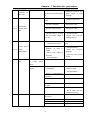
For a 6mm moving in a revolution, it
The
needs 10÷6=1.6666 revolution; as for
instruction unit must be defined in
2500×4 pulses for a revolution, the
advance by electronic gear ratio. If
instruction
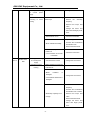
the instruction unit is set for 1 um,
pulse
input
is
mechanical
condition
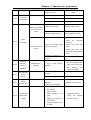
1.6666×2500×4=16666 pulses. And
10mm
moving
the operation must be executed in the
10mm÷1um=10000 pulses.
and
needs
upper device.
3)
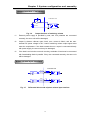
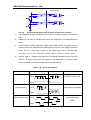
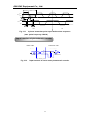
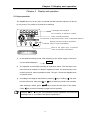
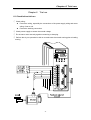
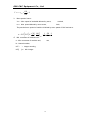
Set servo on(SON) for ON on condition that no alarming and abnormity occurs. The
motor will be actuated for zero speed.
4)
Input low frequency pulse to make the motor run in a low speed, and check whether
the motor speed is the setting one. Stop inputting low frequency pulse to see
whether the motor stops. Adjust the parameter if the motor runs in a low speed.
50