1
111.6.1.1
Mechanical Considerations
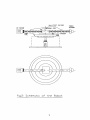
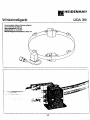
The structure of this three dimensional torque sensor is in
aluminum. It has been built with two principle structures; a base
which can be mounted on the robot arm and a cover on which the
"helptool" can be fixed.
Both parts are linked together through connection bars. Six
bars are needed to ensure a static position of the two parts, the
use of more bars would be detrimental to the swiftness and the
symmetric structure of the sensor.
The main problem with the construction of the sensor is to get
the best orientation for the connection bars, because of the
small volume required for the interface.
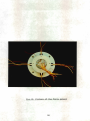
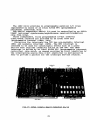
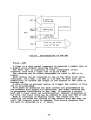
The mechanical part consists of a circular base which is
connected to the nucleus by four bars, itself connected to the
upper ring with four bars.
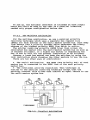
On each bar there are two strain gages as close as possible to
the nucleus. Together they form a half Wheatstone bridge.
If forces or moments are performed between the two rings, they
cause elastic distortions which are converted into voltage by the
strain gages.
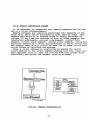
with the eight signals, the constraint on the sensor can be
calculated by using a transformation matrix which links the eight
voltages to the six components of the constraint matrix.
As said above, six bars are sufficient to calculate the efforts
applied on the sensor. The use of eight bars permits the
calculation of the same constraints, but as we can see in the
transformation matrix, there are many null terms. So the
calculation time is greater and the link between the two rings is
hyperstatic.
Despite the fact that steel offers a better linearity in its
deformation, aluminum is used because of its lower modiolus of
elasticity. Furthermore it doesn't corrode and is easy to tool.
Moreover, with the use of aluminum, we can get specific strain
gages.
19