1
192
Axis Properties
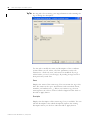
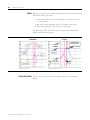
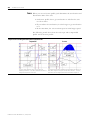
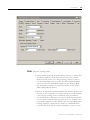
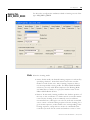
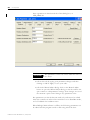
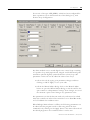
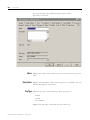
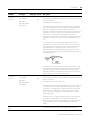
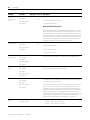
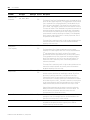
• Absolute: (AXIS_SERVO_DRIVE, and AXIS_SERVO when
associated with a 1756-HYD02 [LDT feedback] or 1756-M02AS
[SSI feedback] module only) In this mode, the absolute homing
process establishes the true absolute position of the axis by
applying the configured Home Position to the reported position
of the absolute feedback device. The only valid Home Sequence
for an absolute Homing Mode is immediate. In the LDT and SSI
cases, the absolute homing process establishes the true absolute
position of the axis by applying the configured Home Position
less any enabled Absolute Feedback Offset to the reported
position of the absolute feedback device. Prior to execution of
the absolute homing process using the MAH instruction, the axis
must be in the Axis Ready state with the servo loop disabled.
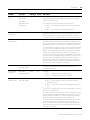
IMPORTANT
For the SSI feedback transducer no physical marker pulse
exists. However, a pseudo marker reference is established by
the M02AS module firmware at the feedback device’s roll over
point. A single-turn Absolute SSI feedback device rolls over at
its maximum “turns count” = 1 rev. A multi-turn Absolute SSI
feedback device (there are multiple revs or
feedback-baseunit-distances) the device rolls over at its
maximum “turns count” which is usually either 1024 or 2048.
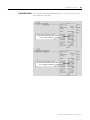
If you need to establish the rollover of the feedback device, a
ladder rung using an SSV to set Home_Sequence equal “Home
to marker” with the following parameters: Class Name =
SSI_Axis, Attribute_Name = Home_Sequence, and Value = 2
(to Marker) must be added to the application program (cannot
be set Axis Properties and must be reset back to its initial value
0 = Immediate or 1 = Switch after establishing the rollover). The
Home Sequence = to Marker must be used to allow feedback to
travel until the rollover (that is, pseudo marker) is found. This
must be done without the motor attached to any axis as this
could cause up to Maximum number of turn’s before pseudo
marker is found.
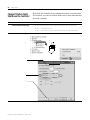
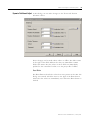
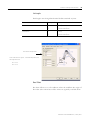
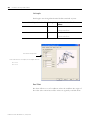
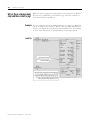
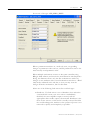
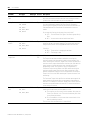
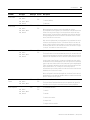
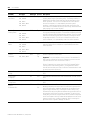
Position
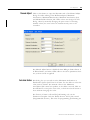
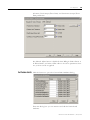
Type the desired absolute position, in position units, for the axis after
the specified homing sequence has been completed. In most cases,
this position is set to zero, although any value within the software
travel limits can be used. After the homing sequence is complete, the
axis is left in this position.
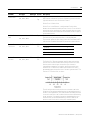
If the Positioning mode (set in the Conversion tab) of the axis is
Linear, then the home position should be within the travel limits, if
enabled. If the Positioning mode is Rotary, then the home position
should be less than the unwind distance in position units.
Publication LOGIX-UM002B-EN-P - January 2007