1
3-4 Connections
3-4
Connections
3-4-1
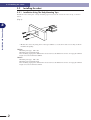
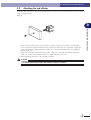
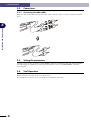
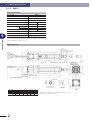
Connecting the robot cables
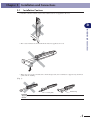
Plug the cable from robot body into the robot cable connector, then cover the connection with the
hood.
Installation and Connections
3
3-5
Setting the parameters
Specify a load capacity parameter setting (PRM3) which is equivalent to the sum of the end effector and workpiece weights. For setting procedure details, refer to the ERCD/ERCX controller
user's manual.
3-6
Trial Operation
Execute a return-to-origin operation.
Begin automatic operation in the low-speed mode.
If no problems are observed, execute high-speed automatic operation.
3-
6