1
VERTEX ANTENNENTECHNIK GMBH
Doc.No.
Version:
OM1002114-21320
1.3
2. HEXAPOD KINEMATICS
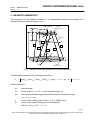
The kinematics of the AMiBA telescope is a mathematical optimized kinematics of a
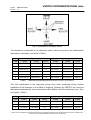
hexapod structure which is shown in Fig. 1.
s
Platform
Center of Gravity
4
5
6
Upper
Universal Joints
3
a
R1
1
α1o
2
Jackscrew
1
Y’
D
h
6
X’
3
4
2
5
Z
5
4
3
α1u
6
R2
Y
2
1
Lower
Universal Joints
X
Fig. 1: Hexapod coordinate system and mount parameters
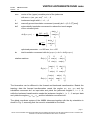
The kinematical equation of the hexapod structure is
Li =
(Rz(ϕ
az
)
) Rx(ϕ zen ) Rz(ϕ pol ) Rz(ϕ az )T (mov i − v ) + v + dv − fix i , i = 1,...,6
with the notations
ϕaz
azimuth angle
ϕzen
zenith angle (ϕzen = π/2 - ϕel with elevation angle ϕel)
ϕpol
hexa-pol polarisation angle (alternatively obs-pol polarisation angle
ϕpol_Obs = ϕpol - ϕaz)
v
vector of the rotation point D with v = (0, 0, 3580)T [mm]
fix
vector of the (lower) fixed point of the jackscrew
with fixi = (xfi, yfi, zfi)T, i = 1,...,6
page 2
NOTE: THIS DOCUMENT CONTAINS PROPRIETARY INFORMATION AND MAY NOT BE DISCLOSED WITHOUT THE WRITTEN
CONSENT OF VERTEX ANTENNENTECHNIK GmbH, DUISBURG