1
Safety
Information
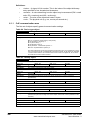
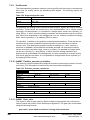
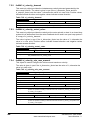
7.3.17 0x60FB Position_control_parameter_set object
Table 7.30 Position_control_parameter_set object
0x60FB
Position_control_parameter_set
Access: RO
Range: N/A
Size: Unsigned 8
Default:
2
Description:
The number of control loop parameters.
Introduction
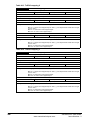
Sub-index 0
Unit: N/A
Access: RW
Range: 0 to 65535
Size: Unsigned 16
Default:
2500
Description:
The position controller proportional gain.
Mechanical
Installation
Sub-index 1
Unit: 0.01 rad/s/rad
Sub-index 2
Range: 0 to 65535
Size: Unsigned 16
Default:
1000 (i.e. a gain of 1)
Description:
The position controller speed feed forward gain.
Electrical
Installation
Access: RW
Unit: 1 / 1000
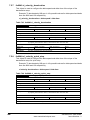
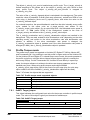
The position_demand_value object contains the value supplied by either the
interpolated position mode or the profile position mode (in user units). It is updated
every control loop cycle. This object can be mapped as cyclic data.
Interpolated position mode
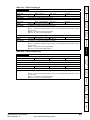
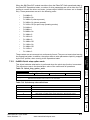
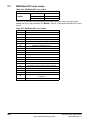
Table 7.31 Supported Interpolated position mode objects
Name
0x60C0
interpolation_submode_select
0x60C1
interpolation_data_record
0x60C2
interpolation_time_period
Advanced
features
7.4.1
Index
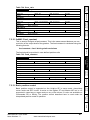
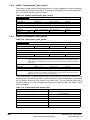
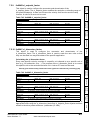
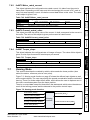
0x60C0 Interpolation_sub-mode_select
Table 7.32 0x60C0 Interpolation_sub-mode_select
Access: RW
Interpolation_sub-mode_select
Range: 0
Size: Signed 16
Diagnostics
0x60C0
Drive profile (DSP-402)
support
Interpolated position mode operates on the Unidrive SP in servo mode, closed-loop
vector mode and RFC mode. This mode also operates on the Digitax ST and Mentor
MP. Table 7.31 lists the objects that are supported:
Protocols
7.4
Getting Started
The APC position controller kernel is used by the basic internal position control.
Unit: N/A
Default:
0 (Linear interpolation)
Description:
Specifies the interpolation type. The values have the following meanings:0 = Linear
Interpolation.
Quick
Reference
Glossary Of
Terms
Index
SM-EtherCAT User Guide
Issue Number: 2
www.controltechniques.com
39