1
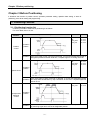
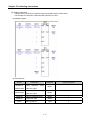
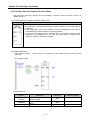
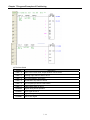
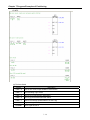
Chapter 6 Positioning Monitoring Package
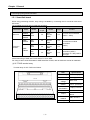
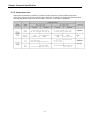
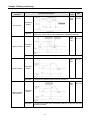
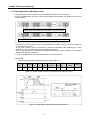
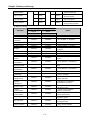
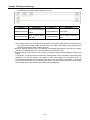
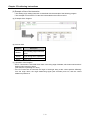
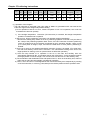
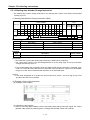
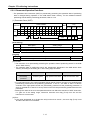
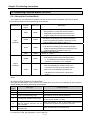
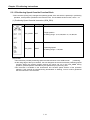
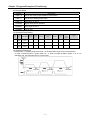
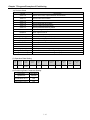
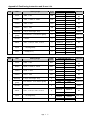
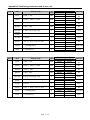
Item
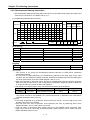
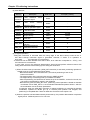
Spd override
Description
Command Remark
SOR
APM_SOR
5.2.13
POR
APM_POR
5.2.12
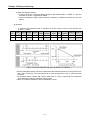
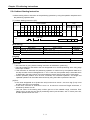
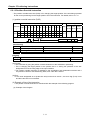
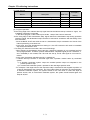
Spd override with Changes the operation speed at the speed value set in the set
PSO
position
position
APM_PSO.
5.2.14
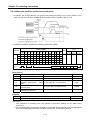
Conducts home return as the home return method set in the
ORG
positioning parameter
APM_ORG
5.2.1
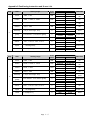
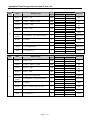
Sets the current position as the fixed home
FLT
APM_FLT
5.2.2
PRS
APM_PRS
5.2.18
SNS
APM_SNS
5.2.16
Conducts inching operation to the set position (inching amount) at
INCH
the inching speed set in the positioning parameter
APM_INC
5.2.15
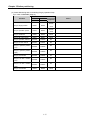
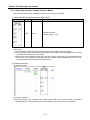
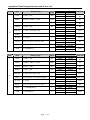
Pos override
Home return
FLT
Position preset
Start step No.
Inching
Overrides the speed at the set speed value
Overrides the position at the set position value
Presets the current position with the set value
Changes the start step with the set step
Conducts jog operation at the jog speed set in the parameter
5.3.14
5.3.13
5.3.15
5.3.2
5.3.3
5.3.19
5.3.17
5.3.16
-
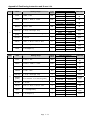
Jog
Reverse
high speed
Reverse
low speed
Jog stop
Normal low
speed
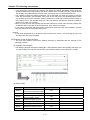
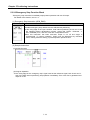
Spd position
conversion
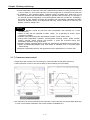
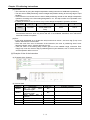
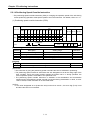
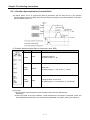
Changes from speed control to position control
Position spd
conversion
Changes from position control to speed control
Normal
high
speed
VTP
APM_VTP
5.2.7
PTV
APM_PTV
5.2.8
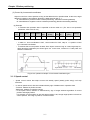
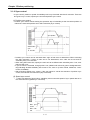
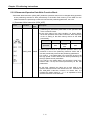
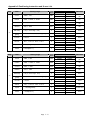
Spd synchronous Speed synchronous operation at the set main axis, speed ration
SSS
operation
and delay time
APM_SSS
Position
synchronous
operation
Speed synchronous operation at the set main axis, step and
SSP
position
APM_SSP
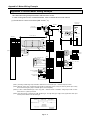
Simultaneous start Simultaneous start with the operation step set for each axis
Straight
interpolation
operation
5.3.8
5.3.9
5.2.11
5.3.12
5.2.10
5.3.11
SST
APM_SST
5.2.6
Straight interpolation operation for axes X and Y with the set
LIN
operation step
APM_LIN
5.2.5
6-4
5.3.7
5.3.6