1
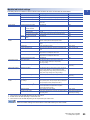
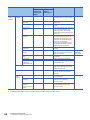
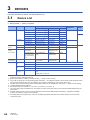
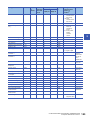
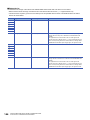
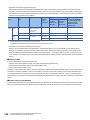
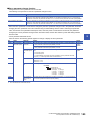
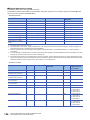
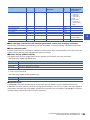
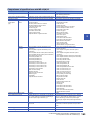
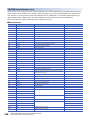
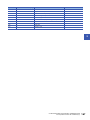
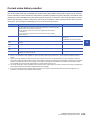
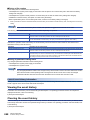
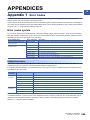
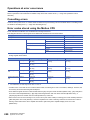
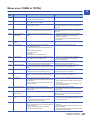
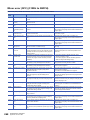
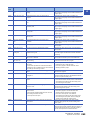
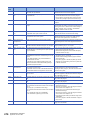
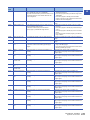
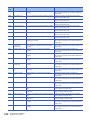
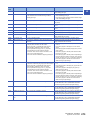
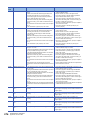
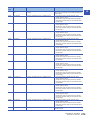
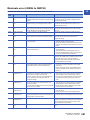
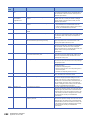
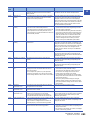
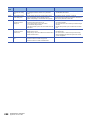
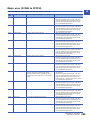
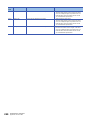
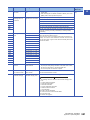
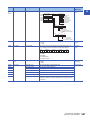
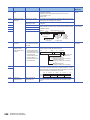
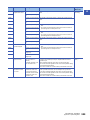
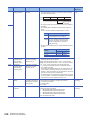
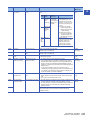
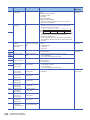
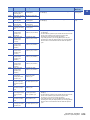
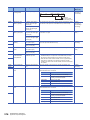
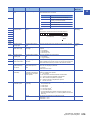
Error code Error name Error details and cause 1993H Software stroke limit + • The feed current value exceeded the stroke limit range at start. • The feed current value exceeded the stroke limit range when controlling. Only the axes which exceeded the stroke limit range are stored in case of the circular interpolation/helical interpolation. All of the interpolations are stored in case of the linear interpolation. • Set within the stroke range by the JOG operation. Or set within the stroke range by the home position return or current value change. • Correct the stroke limit range or movement amount setting so that positioning control is within the range of the stroke limit. 1995H Software stroke limit - • The feed current value is lower than the stroke lower limit value at start. • The feed current value is lower than the stroke lower limit value when controlling. Only the axes which exceeded the stroke limit range are stored in case of the circular interpolation/helical interpolation. All of the interpolations are stored in case of the linear interpolation. • Set within the stroke range by the JOG operation. Or set within the stroke range by the home position return or current value change. • Correct the stroke limit range or movement amount setting so that positioning control is within the range of the stroke limit. 1997H Current value change outside range The current value was changed outside the range of 0 to 35999999 (10-5 [degree]) for the degree axis. 19A1H PLC ready OFF start The "[Rq.1120] PLC ready flag" or the "PCPU preparation completion flag" is OFF. 19A4H ABS direction setting error during degree When software stroke limit is invalid, the value outside the range has been set to "ABS direction setting device during degree". 19A6H Start error during home position return incomplete The "[St.1069] Home position return request" is ON if the "Servo program not executed" is selected in the operation setting when the home position is not completed. 19DFH Stop function valid setting error for backing side Enable the stop function valid setting to backing side of servo parameter (PT12: TOP1 pressure control function selection 1). 19E0H Pressure control exceed last address error 19E1H Pressure control start error 19E2H Command speed acceleration/deceleration time outside range • The command speed acceleration time of the speedtorque control data is outside the range 0 to 8388608 [ms]. • The command speed deceleration time of the speedtorque control data is outside the range 0 to 8388608 [ms]. • Set the command speed acceleration time of the speedtorque control data within the range 0 to 8388608 [ms]. • Set the command speed deceleration time of the speedtorque control data within the range 0 to 8388608 [ms]. 19E3H Command torque time constant outside range • The command torque time constant (positive direction) of the speed-torque control data is outside the range of 0 to 8388608 [ms]. • The command torque time constant (negative direction) of the speed-torque control data is outside the range of 0 to 8388608 [ms]. • Set the command torque time constant (positive direction) of the speed-torque control data within the range of 0 to 8388608 [ms]. • Set the command torque time constant (negative direction) of the speed-torque control data within the range of 0 to 8388608 [ms]. 19E6H Target position change request prohibited acceleration/deceleration method The target position change request (CHGP) is executed to the program where the following acceleration/deceleration system is set. • FIN acceleration/deceleration • Advanced S-curve acceleration/deceleration 19E7H Unsupported stopper control Switching to the stopper control was requested to the servo amplifier which unsupported to the stopper control. Use the available stopper control for servo amplifier. 19E8H Stroke limit invalid axis circular/helical interpolation execution error The circular interpolation or helical interpolation was started in the invalid axis of stroke limit. Make the stroke limit valid for the control unit degree axis starts the circular interpolation or helical interpolation. • The difference between last address and home position exceed motor encoder pulse unit (2-31 pulse to motor encoder for 10 rev.). • The difference between last address and actual current value exceed motor encoder pulse unit (2-31pulse). Necessary setting value for pressure control starting is outside the range. Corrective action Operate within the range of 0 to 35999999 (10-5[degree]). • Set the Motion CPU to RUN. • Turn the "[Rq.1120] PLC ready flag" on. Set the ABS direction setting device during degree within the range. • After the home position return is accomplished, execute the servo program. • For systems that allow the execution of the servo program even if a "[St.1069] Home position return request" is ON, set "Operational setting for home position return incomplete" of the home position return data setting to "Execute servo program". Disable the stop function valid setting for backing side. Correct the value of last address to make it within the setting range of limit value. Correct the setting value. • Do not execute the target position change to the program where the FIN acceleration/deceleration or the advanced S-curve acceleration/deceleration is set. • Set the acceleration/deceleration system of the parameter block or the servo program to the trapezoid/ S-curve acceleration/deceleration. APPENDICES APPENDIX Appendix 1 Error Codes 259 A