1
Command Reference
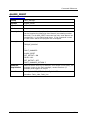
Servo
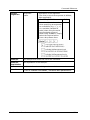
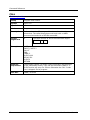
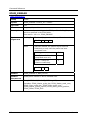
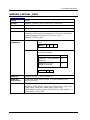
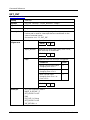
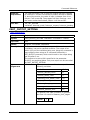
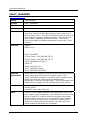
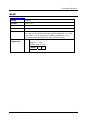
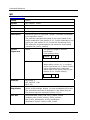
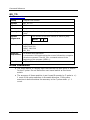
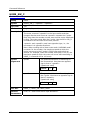
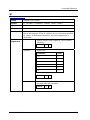
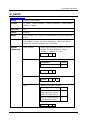
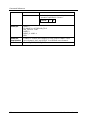
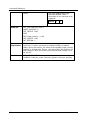
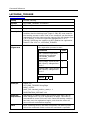
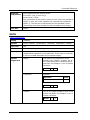
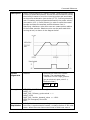
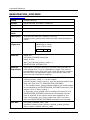
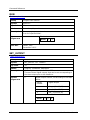
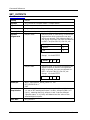
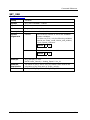
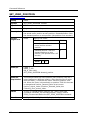
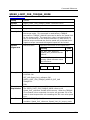
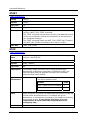
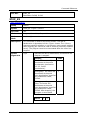
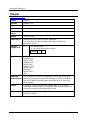
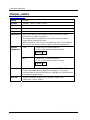
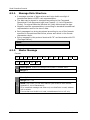
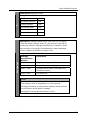
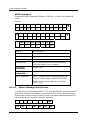
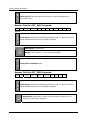
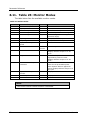
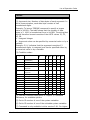
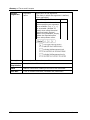
This argument defines the motor state after the
motion actually stops:
Setting
Code
Servo ON: The motor
remains enabled.
0
Servo OFF: The motor is
disabled.
1
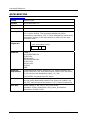
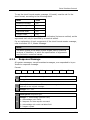
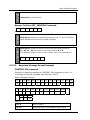
Serial
1
U
Notes
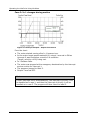
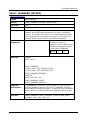
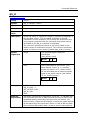
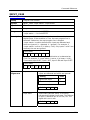
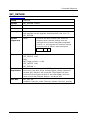
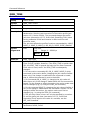
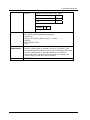
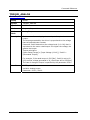
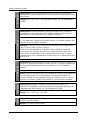
Unless <Type> is set to Emergency + Program Stop, the program
line following the STOP_EX command will only be executed once
the theoretical deceleration has been completed.
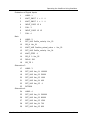
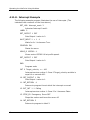
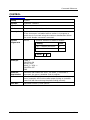
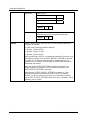
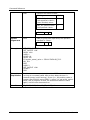
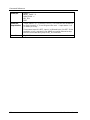
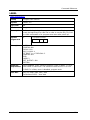
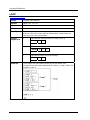
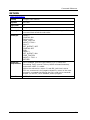
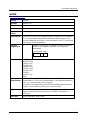
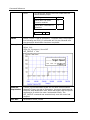
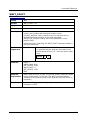
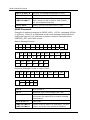
Example
SLIDE 1000
DELAY 200
STOP_EX Emergency Servo OFF
SET_OUTPUT 1 ON
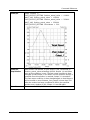
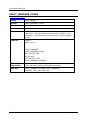
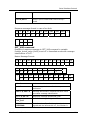
Example
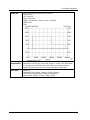
Explanation
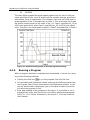
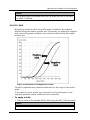
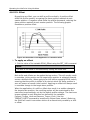
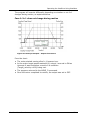
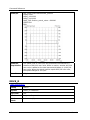
A STOP_EX command was issued 200 ms after motion started.
Because <Type> was set to Emergency, the motor decelerated at
the quick stop deceleration rate, which was higher than the profile
acceleration at which the motor accelerated initially. The
SET_OUTPUT command was executed only once the motor had
stopped.
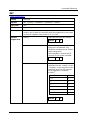
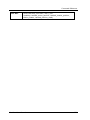
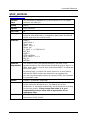
See Also
Parameters Pn2A8, Pn2A9
160
XtraWare User Manual