1
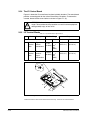
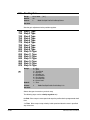
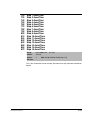
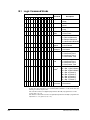
Enable Jerk = Enables/disables the jerk limit in the current limiter that helps to
eliminate overcurrent trips on fast accelerations. Disable this feature if your application
requires the actual acceleration of the motor to be faster than .25 sec. In non-FVC
Vector modes, disabling jerk removes a short S-curve at the start of the accel/decel
ramp.
Ixo AutoCalc = Reserved
Xsistor Diag = Enables/disables power transistor power diagnostic tests that execute
at each Start command.
Rs Adapt = (FVC w/Encoder only) Disabling may improve torque regulation at lower
speeds (although this is typically not needed).
Mtr Lead Rev = Reverses the phase rotation of the applied voltage, effectively
reversing the motor leads.
PWM Freq Lock = Keeps the PWM frequency from decreasing to 2 kHz at low
operating frequencies in FVC Vector mode without encoder.
57
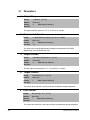
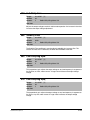
Flux Up Mode
Range:
0 = Manual
1 = Automatic
Default:
0 = Manual
Access:
2
See also:
53, 58
Path: Motor Control>Torq Attributes
Manual (0): Flux is established for Flux Up Time (58) before acceleration
Auto (1): Flux is established for a calculated time period based on motor nameplate
data. Flux Up Time (58) is not used.
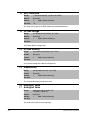
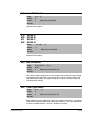
58
Flux Up Time
Range:
0.000 to 5.000 sec [0.001 sec]
Default:
0.000 sec
Access:
2
See also:
53, 58
Path: Motor Control>Torq Attributes
Sets the amount of time the drive will use to try to achieve full motor stator flux. When
a start command is issued, DC current at current limit level is used to build stator flux
before accelerating.
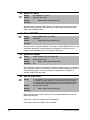
59
SV Boost Filter
Range:
0 to 32767 [1]
Default:
500
Access:
0
Path: Motor Control>Torq Attributes
See also:
Sets the amount of filtering used to boost voltage during Sensorless Vector and FVC
Vector (encoderless) operation.
3-12
DBT Reach Drive User Manual